Skild AI Taps NVIDIA Physical AI to Teach Robots New Tasks From a Single Video


Manufacturing floors, warehouses and production lines rarely stay fixed — tasks change, layouts shift and new products arrive, and most robots can’t keep up without significant reprogramming.

Skild AI’s new S1 robot foundation model helps address this, designed to learn previously unseen, long-horizon tasks from a single video demonstration. The model, launched last week, uses video as input to understand and execute the task without updating its weights or undergoing task-specific post-training — a technique called in-context learning.  

Skild built S1 and conducted the research on NVIDIA AI infrastructure, part of a broader collaboration spanning synthetic data generation, model training, simulation and real-world physical AI deployment. The companies are working together to move adaptable robot intelligence from the lab into factories and other dynamic operating environments.

“Learning by experience, and not preprogramming, is the step change that has happened in robotics,” said Deepak Pathak, cofounder and CEO of Skild AI. “NVIDIA Isaac Lab and NVIDIA Cosmos technologies help Skild create the scalable, diverse experience its robots need to learn across many scenarios and embodiments.”

The launch comes as the company reached a $100 million annual revenue run rate 10 months after its first commercial deployment. In that time, Skild has built more than 60 deployment partnerships with work spanning manufacturing, logistics, inspection, security, food preparation and other applications. 

Learning New Work From One Video

Most industrial robots are built for fixed jobs, so each new product, process or layout requires more data, retraining and validation.

S1 takes a different approach: An operator records a video of the desired task and provides it to the model as a prompt. It interprets the demonstrated intent, objects and sequence, then maps them into actions for the robot in front of it — with no retraining — and often for a task not covered by its pretraining dataset. 

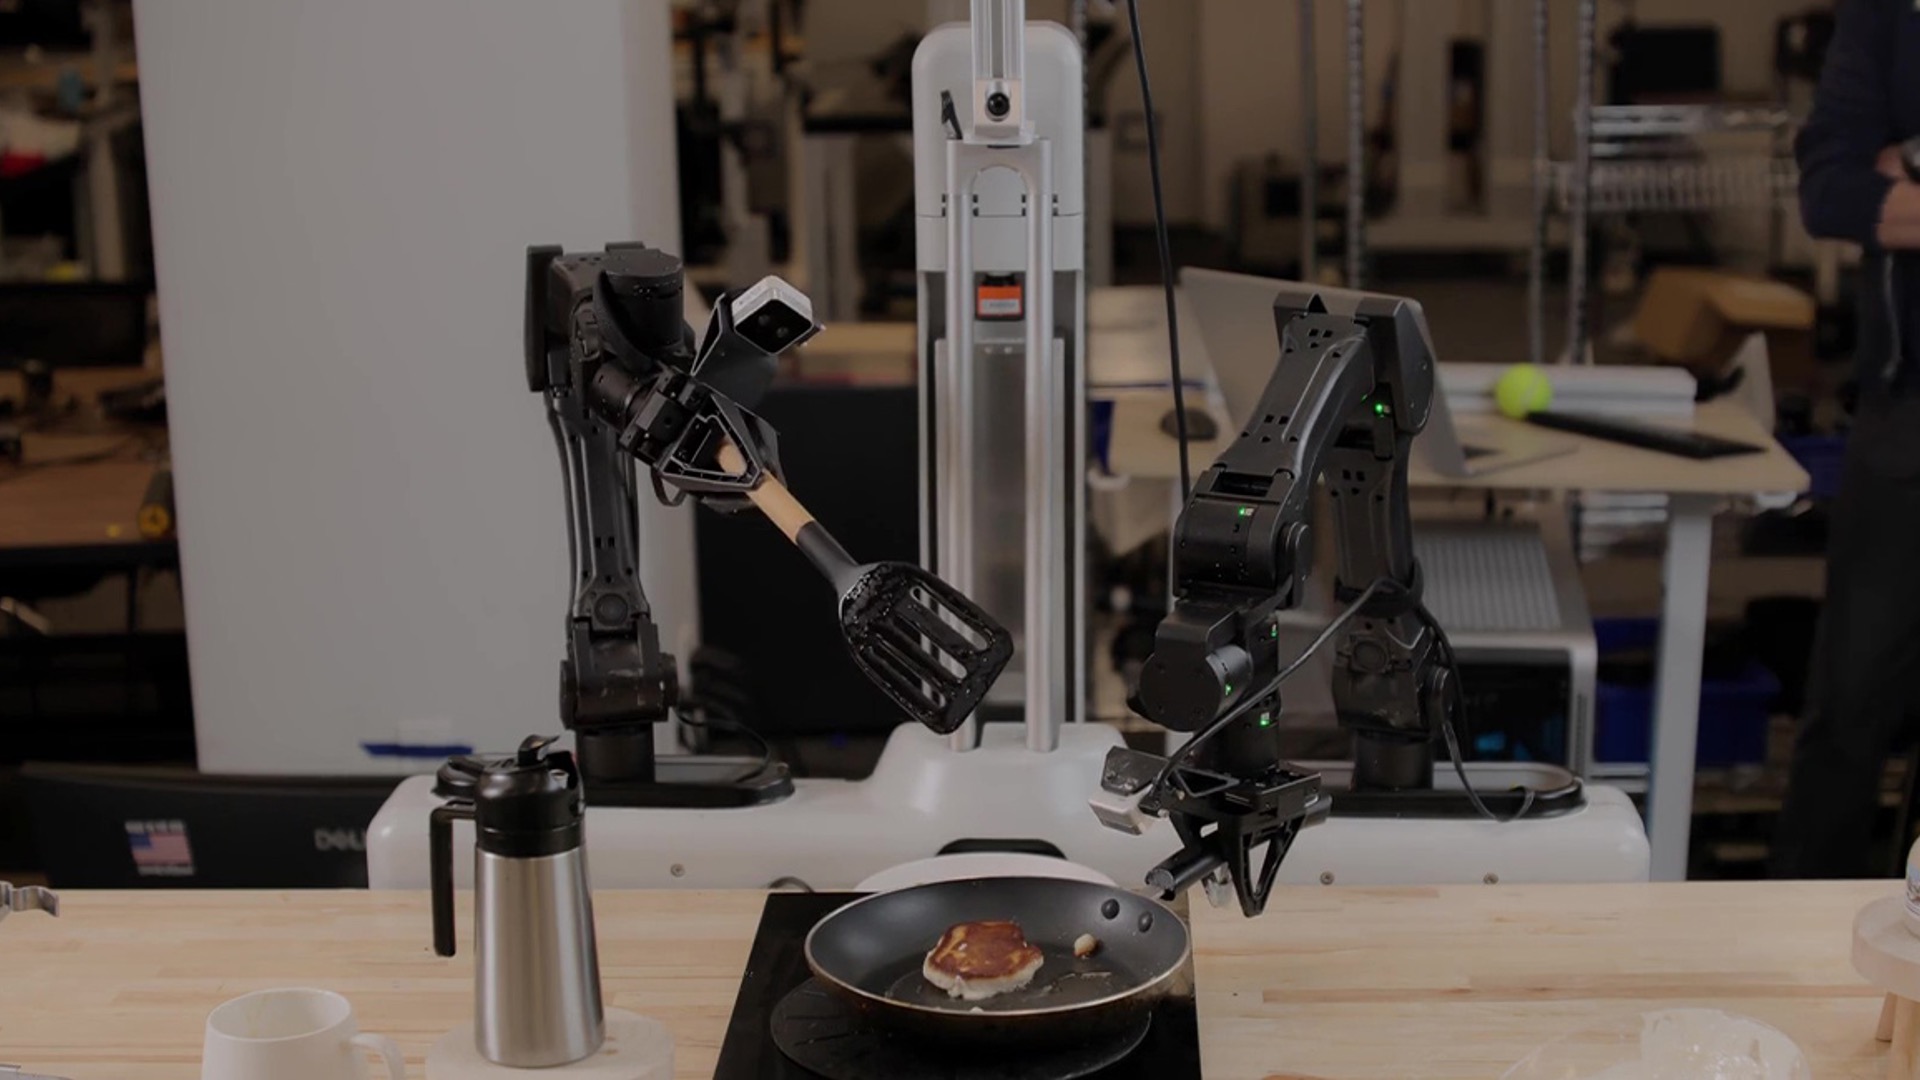
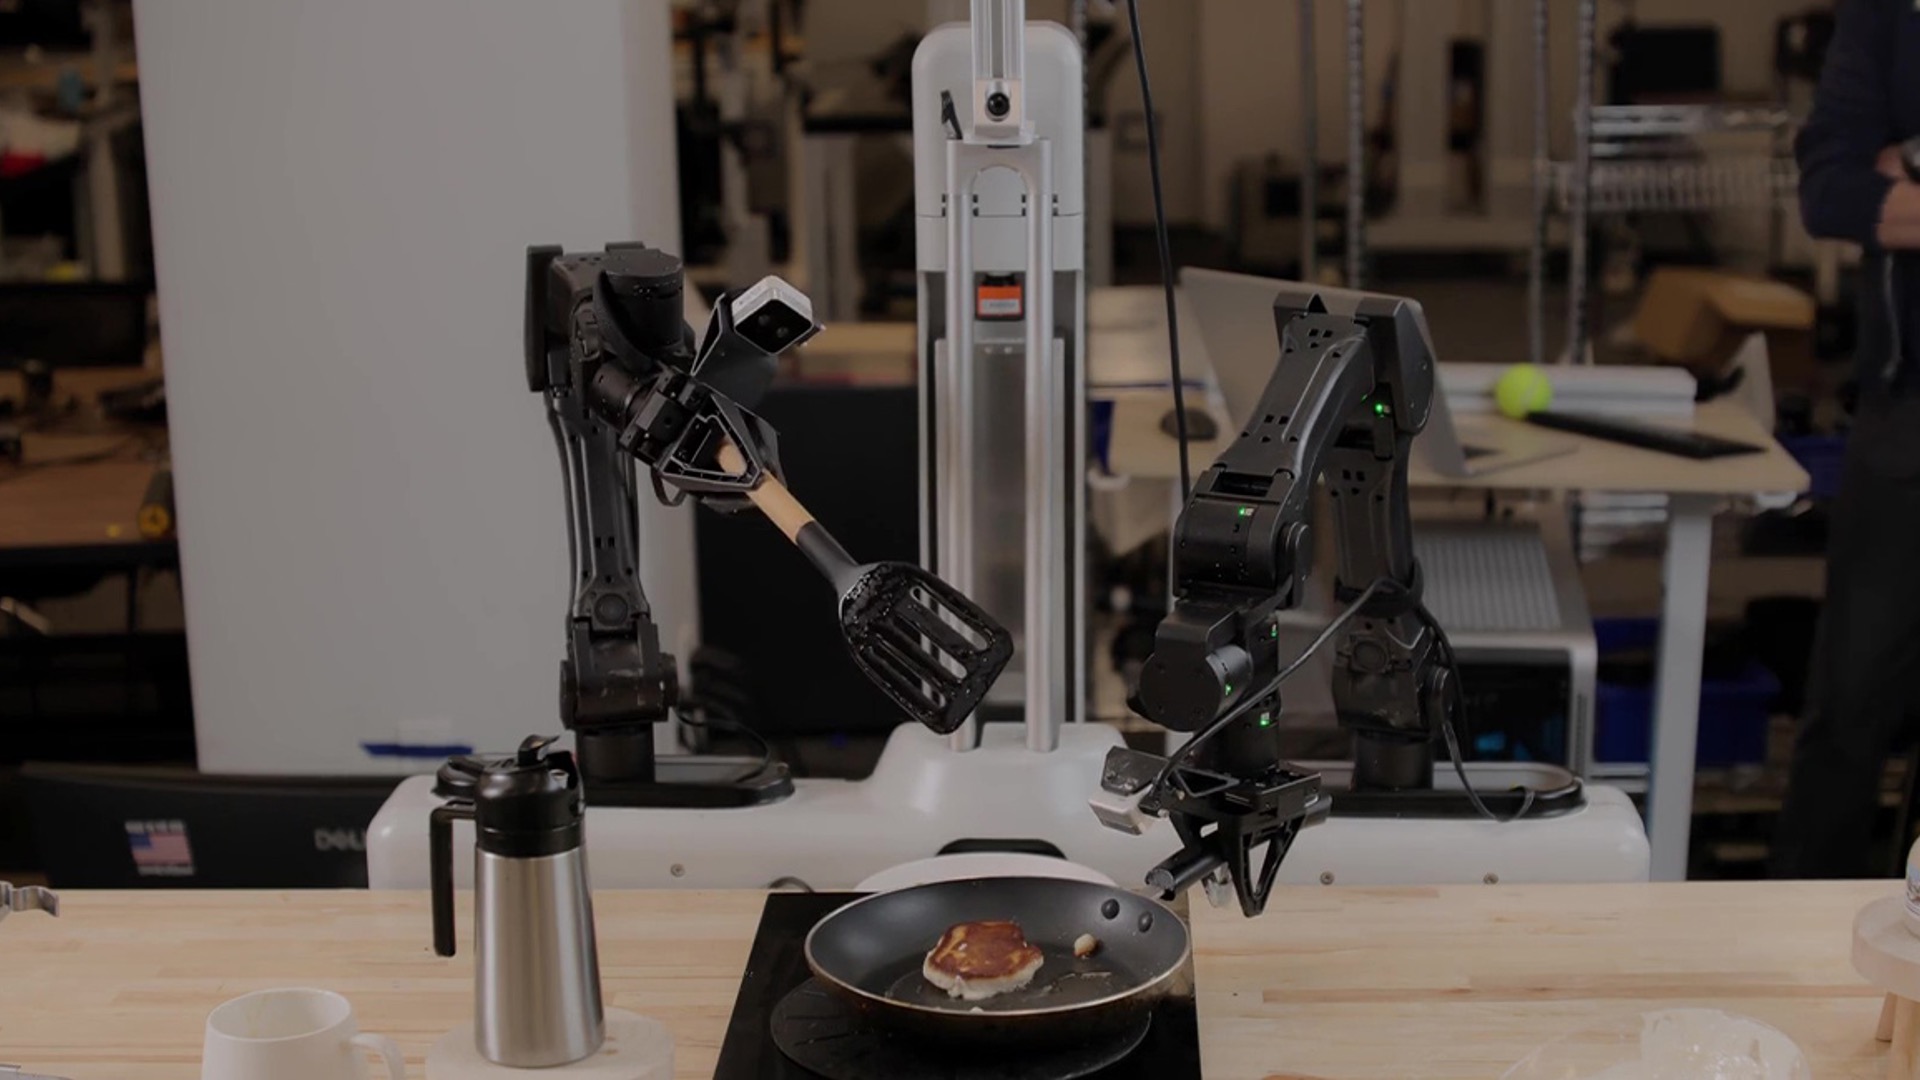
S1 can perform unfamiliar tasks lasting up to 10 minutes, including plant potting, pancake making, pour-over coffee brewing and kit assembly. These tasks can span dozens of manipulation steps and require the robot to compose skills in sequences it hasn’t previously performed. 


In one plant-potting test, the Skild AI team moved from recording the demonstration to autonomous execution on hardware in just 11 minutes. The model can also adjust when objects move, recover from errors and combine skills in sequences that weren’t explicitly programmed.

In Skild’s tests on new, multistep tasks, its S1 robot succeeded about 66% of the time at each step, compared with 9% for a similar AI system — a more than sevenfold improvement. Skild also estimates that showing the robot one short video example can be as useful as giving it roughly 380 hands-on training examples. A person collecting those examples manually could take 50-100 hours.

From Research to Factory Work

S1 breaks the cycle of needing to constantly retrain robots for new factors by letting operators demonstrate new tasks directly without requiring a new dataset or training run for every change. Where customer agreements permit, experience from Skild’s commercial deployments can inform the broader model and help accelerate future deployments.

That work is already in action on the factory floor. Skild, NVIDIA and Foxconn are deploying the Skild Brain on dual-arm manipulators for high-precision assembly of NVIDIA Blackwell systems. In one demonstrated workflow, a robot installs a busbar and limit block, fastens 16 screws and adapts to disturbances across a multistep task. The work requires precise motion, contact-aware control, sequence tracking and recovery when the scene differs from the plan.


NVIDIA Technology Across the Development Cycle

NVIDIA accelerated computing gives Skild the scale to train its shared robot brain using simulation, human video, teleoperation and, where permitted, deployment data. NVIDIA Cosmos open world foundation models help diversify training data and turn video into structured descriptions, while Cosmos Curator helps annotate, filter and organize data at scale.

Skild is extensively using NVIDIA’s open simulation frameworks to train and validate its robot brain before real-world deployment. NVIDIA Omniverse libraries and the NVIDIA Isaac Sim framework provide physically based virtual environments for generating data, testing edge cases and validating behaviors.

Skild further strengthens the skills of its brain through reinforcement learning in Isaac Lab, an open modular robot learning framework. Powered by the Newton physics engine, Isaac Lab helps Skild’s engineers accurately model various physical parameters, such as forces, contact, collision and pressure, and reduce the simulation-to-reality gap.

Skild and NVIDIA are also jointly developing new GPU-accelerated simulation solvers that quickly and accurately model how robots physically touch, grip and manipulate solid objects. They’ll soon be made available to all developers as part of Newton. 

As models move toward production, NVIDIA Nsight tools help engineers find performance bottlenecks during training, and the NVIDIA TensorRT software development kit optimizes inference so robots can respond quickly in the physical world. Together, these technologies connect the data, simulation, training and deployment stages instead of treating them as separate systems.

Read Skild AI’s S1 research and explore the NVIDIA Isaac robotics platform.
NVIDIA GTC Showcases Virtual Worlds Powering the Physical AI Era


Editor’s note: This post is part of Into the Omniverse, a series focused on how developers, 3D practitioners, and enterprises can transform their workflows using the latest advances in OpenUSD and NVIDIA Omniverse.

NVIDIA GTC last week showcased a turning point in physical AI: Robots, vehicles and factories are scaling from single use cases and isolated deployments to sophisticated enterprise workloads across industries. 

At the center of this shift are new frontier models for physical AI, including NVIDIA Cosmos 3, NVIDIA Isaac GR00T N1.7 and NVIDIA Alpamayo 1.5. 

NVIDIA also released the NVIDIA Physical AI Data Factory Blueprint, designed to push the state of the art in world modeling, humanoid skills and autonomous driving, as well as the NVIDIA Omniverse DSX Blueprint for AI factory digital twin simulation.

Open source agentic frameworks such as OpenClaw extend the AI stack all the way to operations — enabling long‑running “claws” that use tools, memory and messaging interfaces to orchestrate workflows, manage data pipelines and execute tasks autonomously on dedicated machines. 

“With NVIDIA and the broader ecosystem, we’re building the claws and guardrails that let anyone create powerful, secure AI assistants,” said Peter Steinberger, creator of OpenClaw, in an NVIDIA press release from GTC. 

OpenUSD is a driving force behind the scalability of physical AI — providing a common, scene‑description language that lets teams bring computer-aided design (CAD) data, simulation assets and real‑world telemetry into a shared, physically accurate view of the world. 

Simulating the AI Factory Before It’s Built

Modern AI factories are complex — spanning thermals, power grids, network load and mechanical systems. Building them on time and on budget becomes much easier when using simulation technology. 

To tackle this, NVIDIA introduced the Omniverse DSX Blueprint at GTC, a reference architecture that unifies simulation across every layer of an AI factory through a single digital twin. This enables operators to optimize performance and efficiency before a rack is installed in the real world.

Compute Is Data: Real-World Data Is No Longer the Moat

Real-world data used to function as a moat for physical AI — but it doesn’t scale. The real world is messy, unpredictable and full of edge cases, and the pipelines to process, simulate and evaluate data are fragmented. The bottleneck isn’t just data — it’s the entire data factory.

To help address this, NVIDIA introduced at GTC its Physical AI Data Factory Blueprint, an open reference architecture that transforms compute into large-scale, high-quality training data. Built on NVIDIA Cosmos open world foundation models and the NVIDIA OSMO operator, it unifies data curation, augmentation and evaluation into a single pipeline, enabling developers to generate diverse, long-tail datasets from limited real-world inputs.

Leading physical AI developers including FieldAI, Hexagon Robotics, Linker Vision, Milestone Systems, Skild AI and Teradyne Robotics are already tapping the blueprint to speed up robotics projects, vision AI agents and autonomous vehicle programs.

Microsoft Azure and Nebius are the first cloud platforms to offer the blueprint, turning world-scale compute into turnkey data production engines.

“Together with cloud leaders, we’re providing a new kind of agentic engine that transforms compute into the high-quality data required to bring the next generation of autonomous systems and robots to life,” said Rev Lebaredian, vice president of Omniverse and simulation technologies at NVIDIA, in this press release. “In this new era, compute is data.”

From OpenUSD to Reality: Seamless Design to Deployment

Converting CAD files to OpenUSD is a critical step in the physical AI pipeline — transforming engineering data into simulation-ready assets that developers can use to build, test and validate robots in physically accurate virtual environments. 

Using tools like the NVIDIA Omniverse Kit software development kit and NVIDIA Isaac Sim, teams can optimize and enrich 3D data for real-time rendering, simulation and collaborative workflows.  

Companies including FANUC and Fauna Robotics are using this seamless CAD-to-OpenUSD workflow to speed up robotic system design and validation.

Transforming Manufacturing and Logistics Through Industrial Digital Twins

“Factories themselves are now robotic systems,” Lebaredian said during his special address on digital twins and simulation at GTC. 

All factories are born in simulation. The NVIDIA Mega Omniverse Blueprint provides enterprises with a reference architecture to design, test and optimize robot fleets and AI agents in a physically accurate facility digital twin before a single robot is deployed on the floor. 

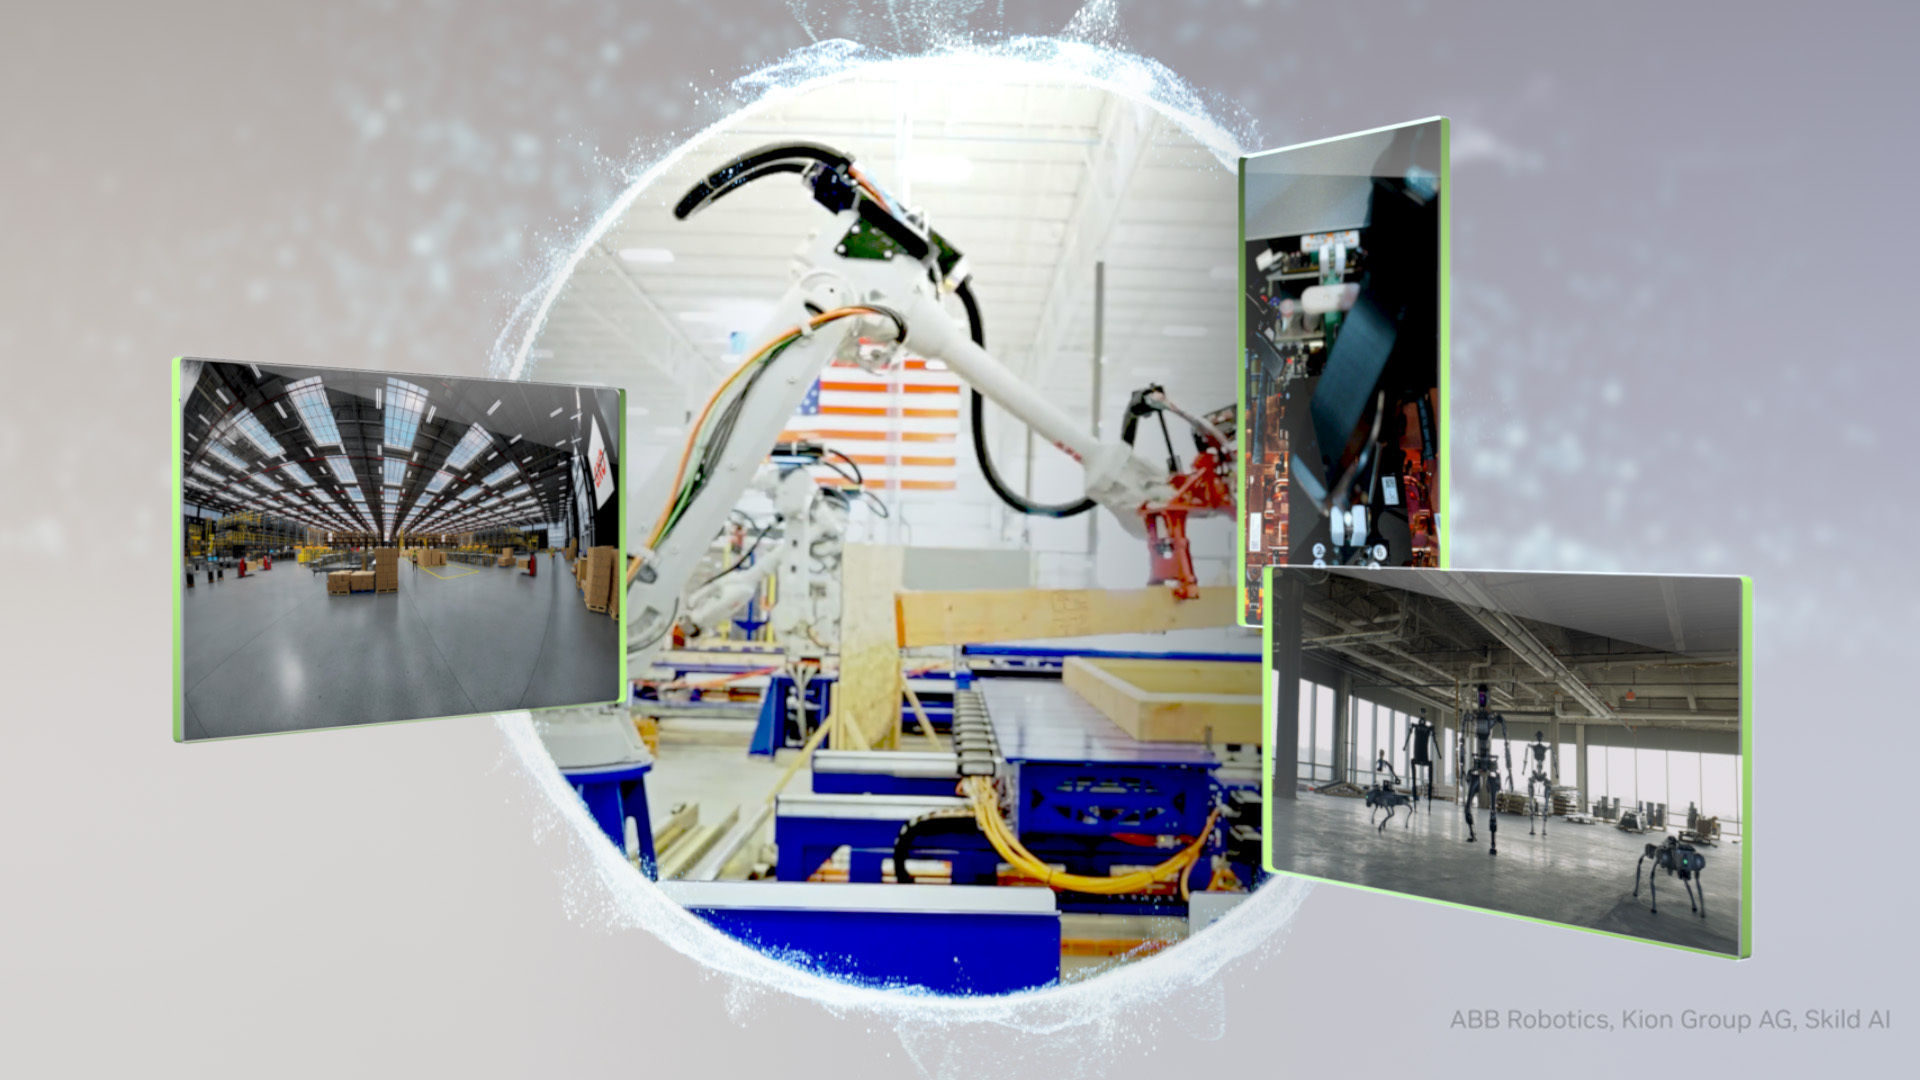
KION, working with Accenture and Siemens, is using this blueprint to build large-scale warehouse digital twins that train and test fleets of NVIDIA Jetson-based autonomous forklifts for GXO, the world’s largest pure-play contract logistics provider. 

Physical AI Steps From Simulation to the Real World

NVIDIA is partnering with the global robotics ecosystem — including leading robot brain developers, industrial robot giants and humanoid pioneers — to enhance production-level physical AI. 

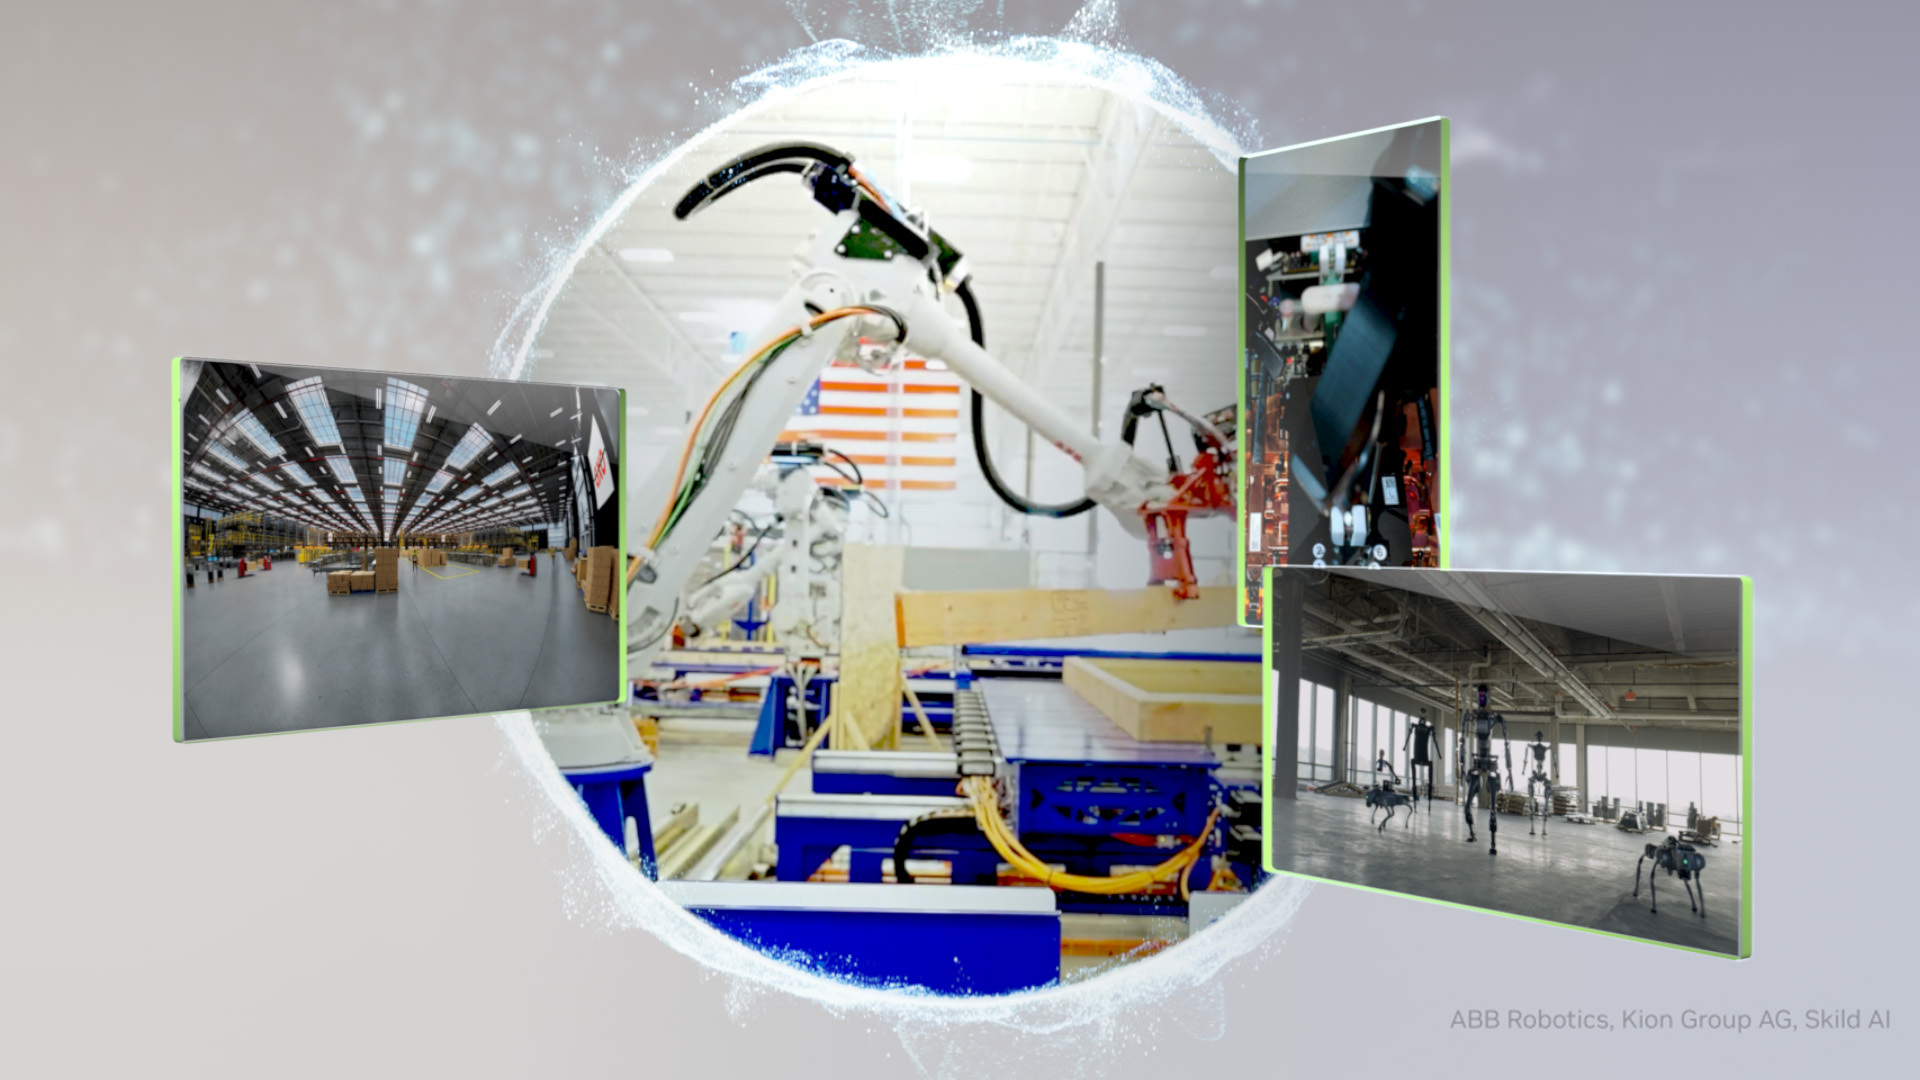
ABB Robotics, FANUC, KUKA and Yaskawa, which have a combined global install base of over 2 million robots, are using NVIDIA Omniverse libraries and NVIDIA Isaac simulation frameworks to validate complex robot applications and production lines through physically accurate digital twins. These companies have also integrated NVIDIA Jetson modules into their controllers to enable real-time AI inference. 

Robot development starts with the robot brains, which is why leading developers including FieldAI and Skild AI are building theirs using NVIDIA Cosmos world models for data generation and Isaac simulation frameworks to validate policies in simulation. 

Meanwhile, Generalist AI is using NVIDIA Cosmos to explore generating synthetic data. This combination allows robots to become proficient in any task — from supply chain monitoring to food delivery — at an exceptional pace. 

Read all of NVIDIA’s announcements from GTC on this online press kit and watch the keynote replay. Catch up on all Physical AI Days sessions from GTC and watch the developer livestream replay.

Into the Omniverse: How Industrial AI and Digital Twins Accelerate Design


Editor’s note: This post is part of Into the Omniverse, a series focused on how developers, 3D practitioners and enterprises can transform their workflows using the latest advancements in OpenUSD and NVIDIA Omniverse.

Industrial AI, digital twins, AI physics and accelerated AI infrastructure are empowering companies across industries to accelerate and scale the design, simulation and optimization of products, processes and facilities before building in the real world.

Earlier this month, NVIDIA and Dassault Systèmes announced a partnership that brings together Dassault Systèmes’ Virtual Twin platforms, NVIDIA accelerated computing, AI physics open models and NVIDIA CUDA-X and Omniverse libraries. This allows designers and engineers to use virtual twins and companions — trained on physics-based world models — to innovate faster, boost efficiency and deliver sustainable products.

Dassault Systèmes’ SIMULIA software now uses NVIDIA CUDA-X and AI physics libraries for AI-based virtual twin physics behavior — empowering designers and engineers to accurately and instantly predict outcomes in simulation.

NVIDIA is adopting Dassault Systèmes’ model-based systems engineering technologies to accelerate the design and global deployment of gigawatt-scale AI factories that are powering industrial and physical AI across industries. Dassault Systèmes will in turn deploy NVIDIA-powered AI factories on three continents through its OUTSCALE sovereign cloud, enabling its customers to run AI workloads while maintaining data residency and security requirements.

These efforts are already making a splash across industries, accelerating industrial development and production processes.

Industrial AI Simulations, From Car Parts to Cheese Proteins 

Digital twins, also known as virtual twins, and physics-based world models are already being deployed to advance industries.

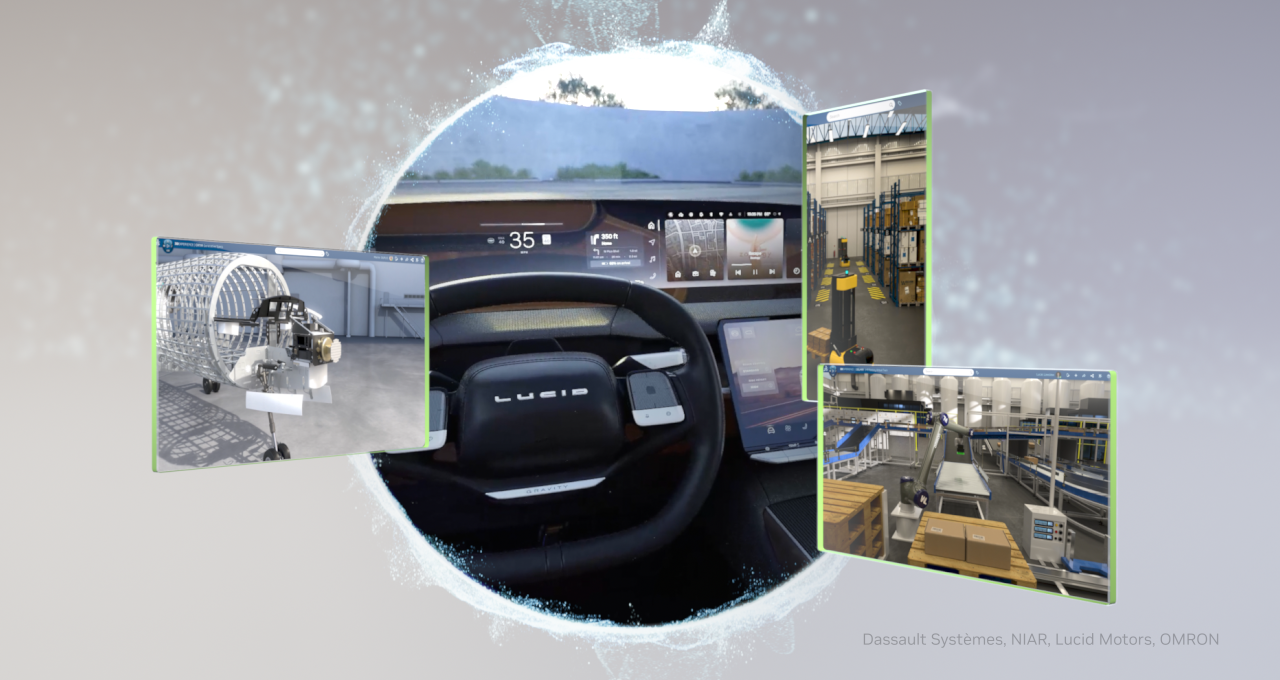
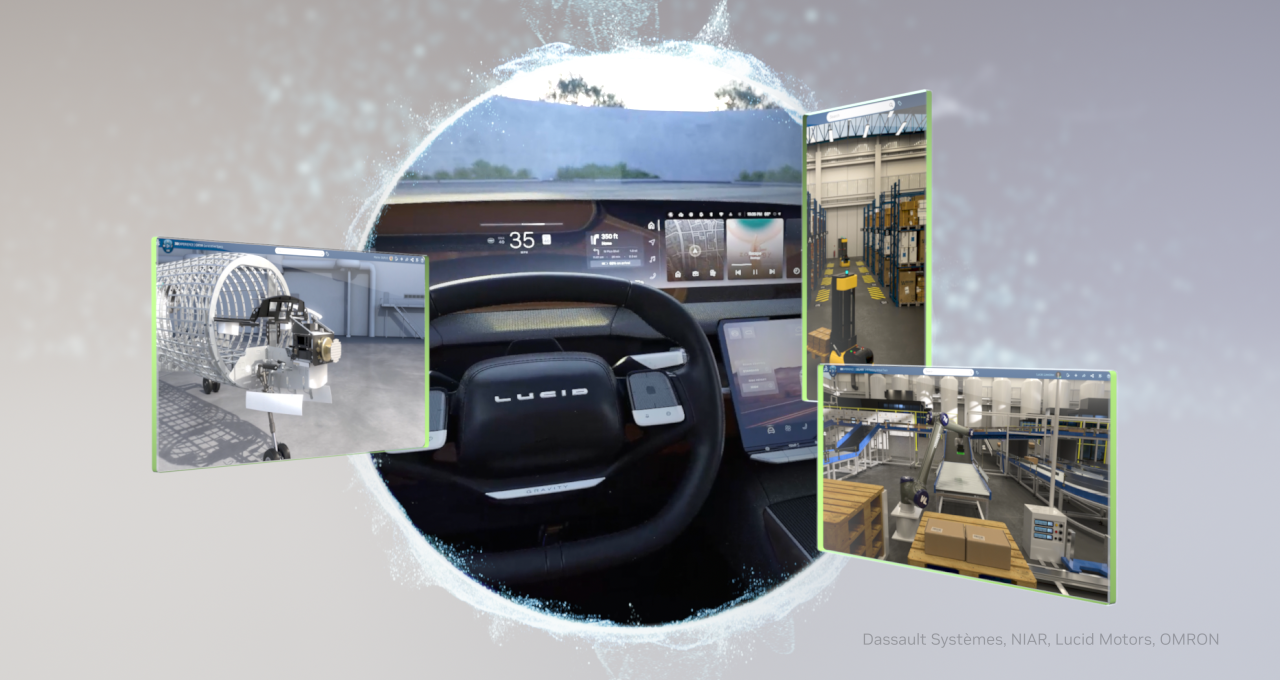
In automotive, Lucid Motors is combining cutting-edge simulation, AI physics open models, Dassault Systèmes’ tools for vehicle and powertrain engineering and digital twin technology to accelerate innovation in electric vehicles. 

In life sciences, scientists and researchers are using virtual twins, Dassault Systèmes’ science-validated world models and the NVIDIA BioNeMo platform to speed molecule and materials discovery, therapeutics design and sustainable food development.

The Bel Group is using technologies from Dassault Systèmes’ supported by NVIDIA to accelerate the development and production of healthier, more sustainable foods for millions of consumers. 

The company is using Dassault Systèmes’ industry world models to generate and study food proteins, creating non-dairy protein options that pair with its well-known cheeses, including Baybel®. Using accurate, high-resolution virtual twins allows the Bel Group to study and develop validated research outcomes of food proteins more quickly and efficiently.

Using accurate, high-resolution virtual twins allows the Bel Group to study and develop validated research outcomes of food proteins more quickly and efficiently.

In industrial automation, Omron is using virtual twins and physical AI to design and deploy automation technology with greater confidence — advancing the shift toward digitally validated production. 

In the aerospace industry, researchers and engineers at Wichita State University’s National Institute for Aviation Research use virtual twins and AI companions powered by Dassault Systèmes’ Industry World Models and NVIDIA Nemotron open models to accelerate the design, testing and certification of aircrafts.

Learning From and Simulating the Real World 

Dassault Systemes’ physics-based Industry World Models are trained to have PhD-level knowledge in fields like biology, physics and material sciences. This allows them to accurately simulate real-world environments and scenarios so teams can test industrial operations end to end — from supply chains to store shelves — before deploying changes in the real world. 

These virtual models can help researchers and developers with workflows ranging from DNA sequencing to strengthening manufactured materials for vehicles. 

“Knowledge is encoded in the living world,” said Pascal Daloz, CEO of Dassault Systemes, during his 3DEXPERIENCE World keynote. “With our virtual twins, we are learning from life and are also understanding it in order to replicate it and scale it.” 

Get Plugged In to Industrial AI

Learn more about industrial and physical AI by registering for NVIDIA GTC, running March 16-19 in San Jose, kicking off with NVIDIA founder and CEO Jensen Huang’s keynote address on Monday, March 16, at 11 a.m. PT. 

At the conference:

  • Explore an industrial AI agenda packed with hands-on sessions, customer stories and live demos. 
  • Dive into the world of OpenUSD with a special session focused on OpenUSD for physical AI simulation, as well as a full agenda of hands-on OpenUSD learning sessions
  • Find Dassault Systèmes in the industrial AI and robotics pavilion on the show floor and learn from Florence Hu-Aubigny, executive vice president of R&D at Dassault Systemes, who’ll present on how virtual twins are shaping the next industrial revolution.
  • Get a live look at GTC with our developer community livestream on March 18, where participants can ask questions, request deep dives and talk directly with NVIDIA engineers in the chat.

Learn how to build industrial and physical AI applications by attending these sessions at GTC.