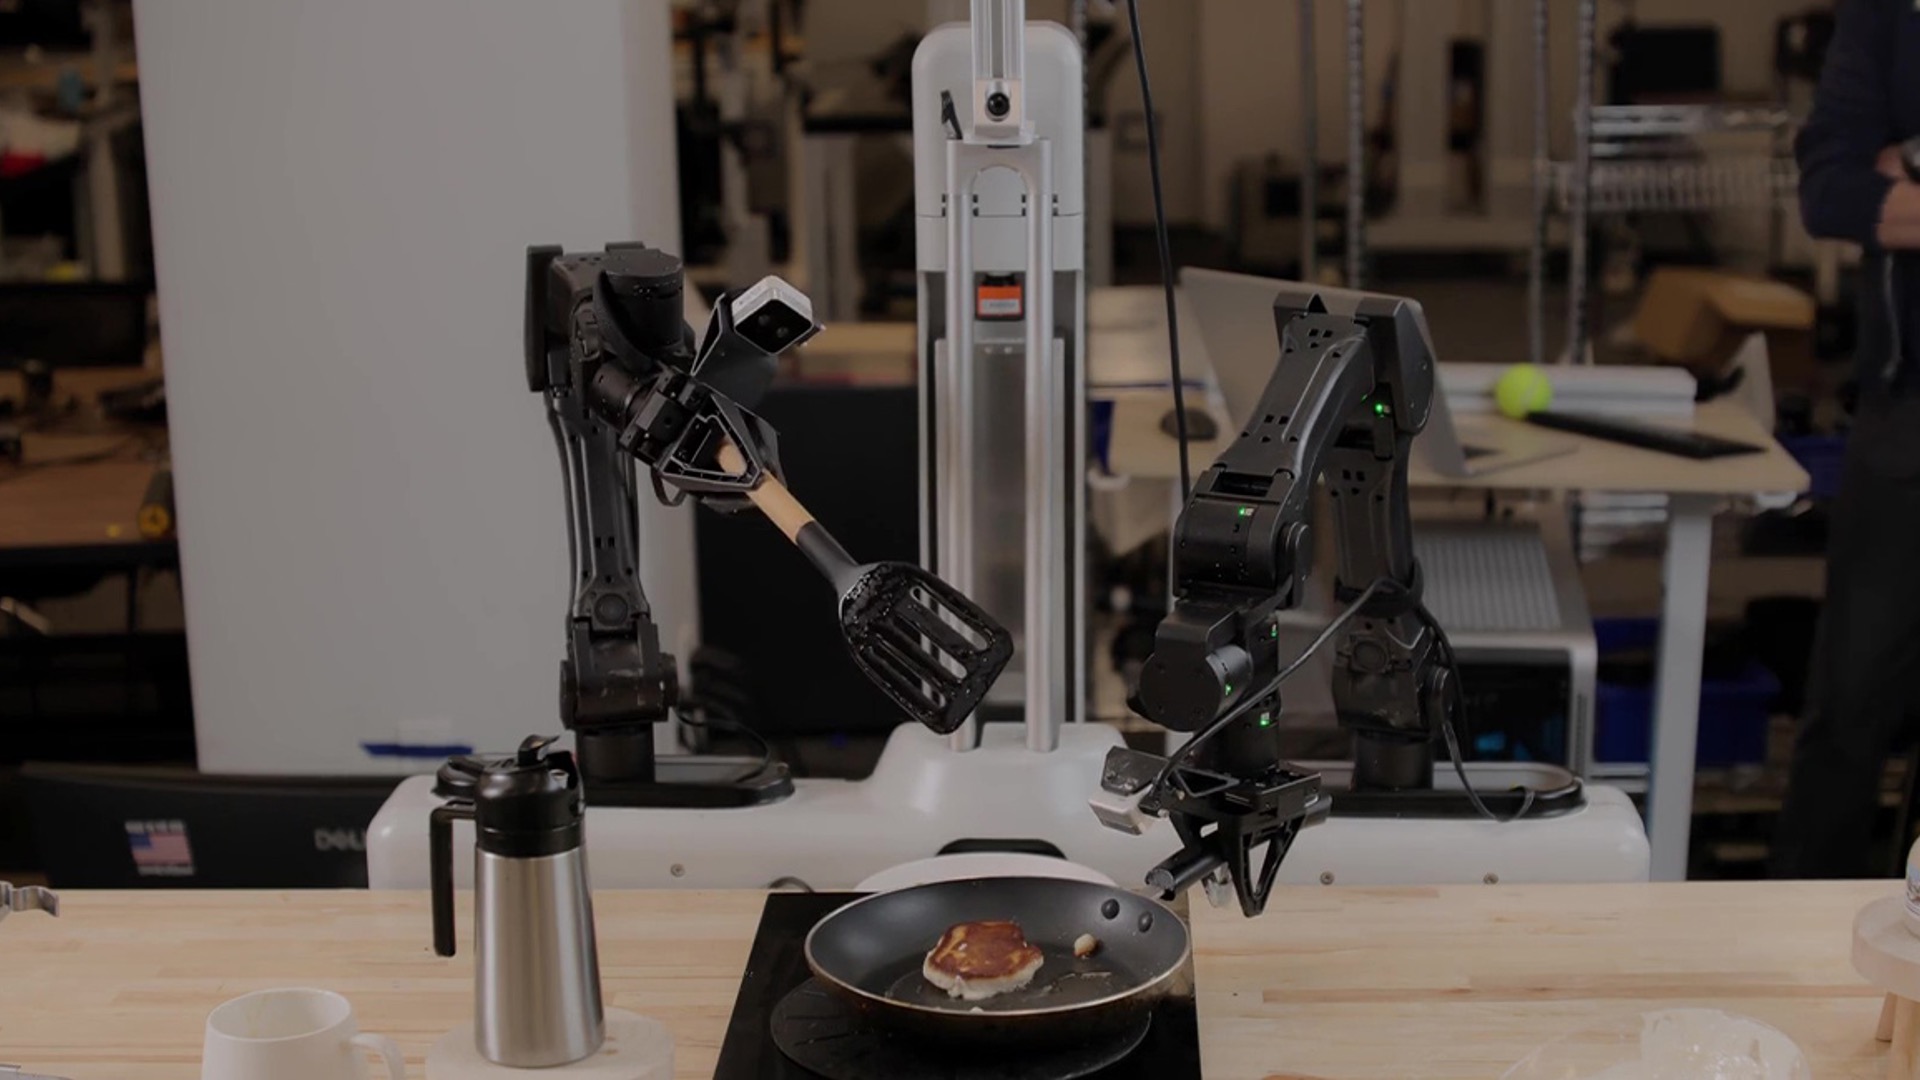
Skild AI Taps NVIDIA Physical AI to Teach Robots New Tasks From a Single Video


Manufacturing floors, warehouses and production lines rarely stay fixed — tasks change, layouts shift and new products arrive, and most robots can’t keep up without significant reprogramming.

Skild AI’s new S1 robot foundation model helps address this, designed to learn previously unseen, long-horizon tasks from a single video demonstration. The model, launched last week, uses video as input to understand and execute the task without updating its weights or undergoing task-specific post-training — a technique called in-context learning.  

Skild built S1 and conducted the research on NVIDIA AI infrastructure, part of a broader collaboration spanning synthetic data generation, model training, simulation and real-world physical AI deployment. The companies are working together to move adaptable robot intelligence from the lab into factories and other dynamic operating environments.

“Learning by experience, and not preprogramming, is the step change that has happened in robotics,” said Deepak Pathak, cofounder and CEO of Skild AI. “NVIDIA Isaac Lab and NVIDIA Cosmos technologies help Skild create the scalable, diverse experience its robots need to learn across many scenarios and embodiments.”

The launch comes as the company reached a $100 million annual revenue run rate 10 months after its first commercial deployment. In that time, Skild has built more than 60 deployment partnerships with work spanning manufacturing, logistics, inspection, security, food preparation and other applications. 

Learning New Work From One Video

Most industrial robots are built for fixed jobs, so each new product, process or layout requires more data, retraining and validation.

S1 takes a different approach: An operator records a video of the desired task and provides it to the model as a prompt. It interprets the demonstrated intent, objects and sequence, then maps them into actions for the robot in front of it — with no retraining — and often for a task not covered by its pretraining dataset. 

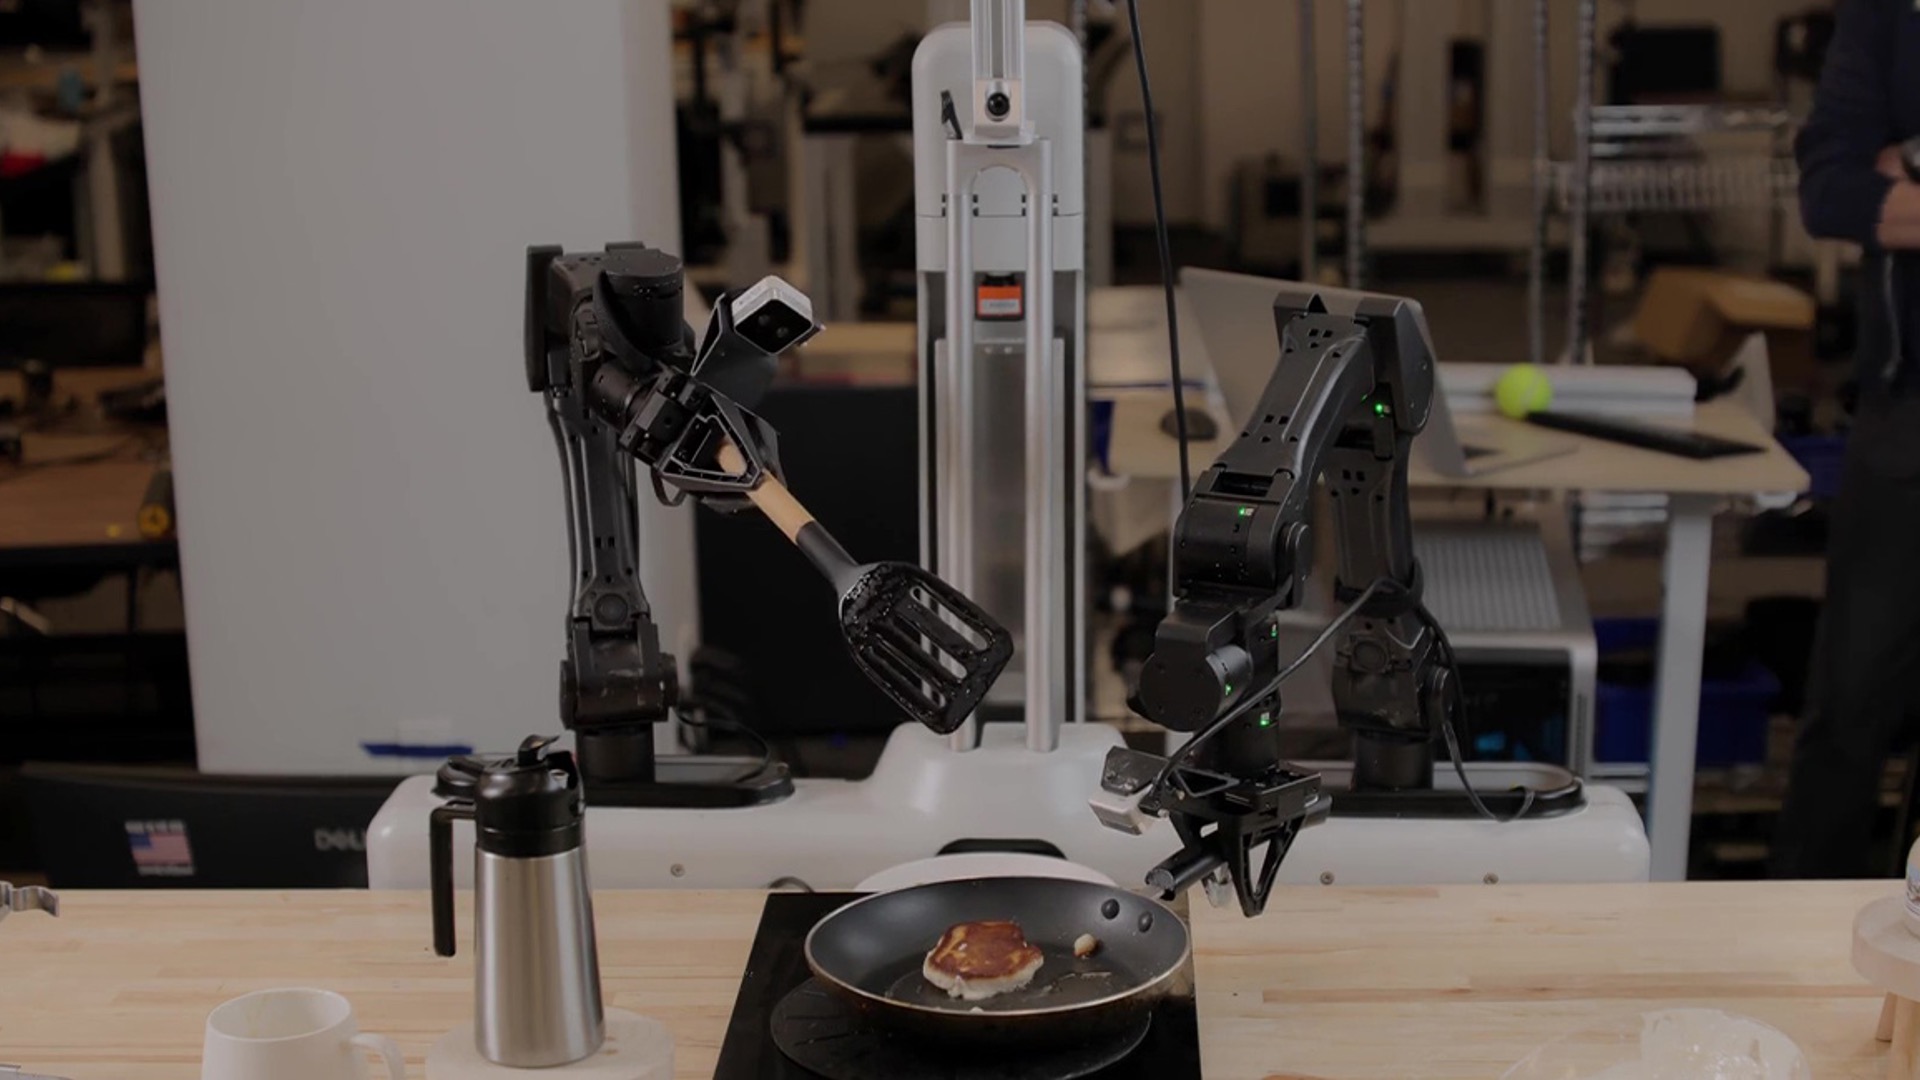
S1 can perform unfamiliar tasks lasting up to 10 minutes, including plant potting, pancake making, pour-over coffee brewing and kit assembly. These tasks can span dozens of manipulation steps and require the robot to compose skills in sequences it hasn’t previously performed. 


In one plant-potting test, the Skild AI team moved from recording the demonstration to autonomous execution on hardware in just 11 minutes. The model can also adjust when objects move, recover from errors and combine skills in sequences that weren’t explicitly programmed.

In Skild’s tests on new, multistep tasks, its S1 robot succeeded about 66% of the time at each step, compared with 9% for a similar AI system — a more than sevenfold improvement. Skild also estimates that showing the robot one short video example can be as useful as giving it roughly 380 hands-on training examples. A person collecting those examples manually could take 50-100 hours.

From Research to Factory Work

S1 breaks the cycle of needing to constantly retrain robots for new factors by letting operators demonstrate new tasks directly without requiring a new dataset or training run for every change. Where customer agreements permit, experience from Skild’s commercial deployments can inform the broader model and help accelerate future deployments.

That work is already in action on the factory floor. Skild, NVIDIA and Foxconn are deploying the Skild Brain on dual-arm manipulators for high-precision assembly of NVIDIA Blackwell systems. In one demonstrated workflow, a robot installs a busbar and limit block, fastens 16 screws and adapts to disturbances across a multistep task. The work requires precise motion, contact-aware control, sequence tracking and recovery when the scene differs from the plan.


NVIDIA Technology Across the Development Cycle

NVIDIA accelerated computing gives Skild the scale to train its shared robot brain using simulation, human video, teleoperation and, where permitted, deployment data. NVIDIA Cosmos open world foundation models help diversify training data and turn video into structured descriptions, while Cosmos Curator helps annotate, filter and organize data at scale.

Skild is extensively using NVIDIA’s open simulation frameworks to train and validate its robot brain before real-world deployment. NVIDIA Omniverse libraries and the NVIDIA Isaac Sim framework provide physically based virtual environments for generating data, testing edge cases and validating behaviors.

Skild further strengthens the skills of its brain through reinforcement learning in Isaac Lab, an open modular robot learning framework. Powered by the Newton physics engine, Isaac Lab helps Skild’s engineers accurately model various physical parameters, such as forces, contact, collision and pressure, and reduce the simulation-to-reality gap.

Skild and NVIDIA are also jointly developing new GPU-accelerated simulation solvers that quickly and accurately model how robots physically touch, grip and manipulate solid objects. They’ll soon be made available to all developers as part of Newton. 

As models move toward production, NVIDIA Nsight tools help engineers find performance bottlenecks during training, and the NVIDIA TensorRT software development kit optimizes inference so robots can respond quickly in the physical world. Together, these technologies connect the data, simulation, training and deployment stages instead of treating them as separate systems.

Read Skild AI’s S1 research and explore the NVIDIA Isaac robotics platform.
NVIDIA and Google Cloud Empower the Next Wave of AI Builders


At this year’s Google I/O conference, NVIDIA and Google Cloud are accelerating the work of more than 100,000 developers in the companies’ joint developer community, which provides curated learning paths, hands-on labs and events that help them build using the full-stack NVIDIA AI platform on Google Cloud. 

Launched at Google I/O last year, the community brings together developers, data scientists and machine learning engineers who want to sharpen their AI skills on the latest NVIDIA and Google Cloud technologies. 

New additions for the community are rolling out this year, including a learning path for using the JAX library on NVIDIA GPUs, a new NVIDIA Dynamo codelab focused on inference optimizations, as well as monthly developer livestreams. 

Over the last year, the community has become a go‑to hub for AI builders using NVIDIA‑accelerated tools for data science and machine learning. The result has been production‑ready retrieval-augmented generation applications on Google Kubernetes Engine (GKE) and instrumenting observability for agent workloads. 

These AI builders are also experimenting with new large language model research and prototyping hybrid on‑premises and cloud inference for real‑world use cases like sports analytics and enterprise data pipelines. 

Building With Google DeepMind’s Gemma, NVIDIA Nemotron and Open Frameworks

NVIDIA and Google Cloud are equipping developers with learning resources and hands-on labs that combine NVIDIA libraries, open models and tools with Google Cloud’s AI platform — so they can build optimized, production‑ready AI applications faster.

For example, developers can accelerate data science and analytics with the NVIDIA cuDF library in Google Colab Enterprise or Dataproc, or deploy multi-agent applications by combining Google DeepMind’s Gemma 4 models, NVIDIA Nemotron open models and Google Agent Development Kit with Google Cloud G4 VMs powered by NVIDIA RTX PRO 6000 Blackwell GPUs in Google Cloud Run or with spot instances. 

NVIDIA and Google Cloud work closely across open frameworks like JAX so developers can build, scale and productize JAX workloads on NVIDIA AI infrastructure on Google Cloud — from single‑GPU experiments to multi‑rack deployments — while getting strong performance and a consistent experience. 

This work extends to Google Cloud AI Hypercomputer, where the MaxText framework uses these JAX optimizations to train large models efficiently on NVIDIA GPUs.

Building on the same foundation, NVIDIA Dynamo on GKE helps developers optimize large-scale inference — including mixture-of-experts models — so they can serve AI applications more efficiently with NVIDIA accelerated infrastructure on Google Cloud.

To help developers get hands-on with these capabilities, a new learning path on running and scaling JAX on NVIDIA GPUs and a new NVIDIA Dynamo on GKE inference codelab will become available next month for members in the Google Cloud and NVIDIA developer community.

Advancing Responsible AI With Google DeepMind’s SynthID and NVIDIA Cosmos

AI agents are increasingly built from a system of AI models — combining proprietary and open source models that reason, plan and act on users’ behalf. 

Amid this shift, trust and transparency are foundational, so developers and organizations can understand how these systems work and what they generate.

NVIDIA was the first industry partner to collaborate with Google DeepMind on SynthID, an AI watermarking technology that embeds robust digital watermarks directly into AI‑generated content, which helps preserve the integrity of outputs from NVIDIA Cosmos world foundation models available on build.nvidia.com.

Cosmos models provide rich 3D perception and simulation capabilities for robots, autonomous machines and other physical AI systems, while SynthID brings content transparency to the imagery and video they rely on. 

Together, they help preserve the integrity of AI‑generated content so developers can build and deploy agentic applications more responsibly across cloud, edge and real‑world environments.

Building on a Full-Stack NVIDIA and Google Cloud Platform

This year, Google I/O is putting the spotlight on new agentic experiences and tools for developers — and NVIDIA and Google Cloud are focused on ensuring builders have the infrastructure, software and learning resources they need to make the most of them. 

For developers in the community building on NVIDIA and Google Cloud, the skills and tools they learn can scale, effortlessly taking projects from prototype to enterprise‑grade workloads. 

At Google Cloud Next, Google Cloud and NVIDIA expanded their full‑stack platform to help developers train, deploy and operationalize agents on Google Cloud. This collaboration includes work on NVIDIA Vera Rubin-powered A5X instances, Google DeepMind Gemini models and more, and is being harnessed by leading AI labs and enterprises including OpenAI, Thinking Machine Labs, Schrodinger, Salesforce, Snap and Crowdstrike. Learn more in this blog.

Join the NVIDIA and Google Cloud developer community to connect with other builders and stay up to date on new tools, developer events and programs.

NVIDIA GTC Showcases Virtual Worlds Powering the Physical AI Era


Editor’s note: This post is part of Into the Omniverse, a series focused on how developers, 3D practitioners, and enterprises can transform their workflows using the latest advances in OpenUSD and NVIDIA Omniverse.

NVIDIA GTC last week showcased a turning point in physical AI: Robots, vehicles and factories are scaling from single use cases and isolated deployments to sophisticated enterprise workloads across industries. 

At the center of this shift are new frontier models for physical AI, including NVIDIA Cosmos 3, NVIDIA Isaac GR00T N1.7 and NVIDIA Alpamayo 1.5. 

NVIDIA also released the NVIDIA Physical AI Data Factory Blueprint, designed to push the state of the art in world modeling, humanoid skills and autonomous driving, as well as the NVIDIA Omniverse DSX Blueprint for AI factory digital twin simulation.

Open source agentic frameworks such as OpenClaw extend the AI stack all the way to operations — enabling long‑running “claws” that use tools, memory and messaging interfaces to orchestrate workflows, manage data pipelines and execute tasks autonomously on dedicated machines. 

“With NVIDIA and the broader ecosystem, we’re building the claws and guardrails that let anyone create powerful, secure AI assistants,” said Peter Steinberger, creator of OpenClaw, in an NVIDIA press release from GTC. 

OpenUSD is a driving force behind the scalability of physical AI — providing a common, scene‑description language that lets teams bring computer-aided design (CAD) data, simulation assets and real‑world telemetry into a shared, physically accurate view of the world. 

Simulating the AI Factory Before It’s Built

Modern AI factories are complex — spanning thermals, power grids, network load and mechanical systems. Building them on time and on budget becomes much easier when using simulation technology. 

To tackle this, NVIDIA introduced the Omniverse DSX Blueprint at GTC, a reference architecture that unifies simulation across every layer of an AI factory through a single digital twin. This enables operators to optimize performance and efficiency before a rack is installed in the real world.

Compute Is Data: Real-World Data Is No Longer the Moat

Real-world data used to function as a moat for physical AI — but it doesn’t scale. The real world is messy, unpredictable and full of edge cases, and the pipelines to process, simulate and evaluate data are fragmented. The bottleneck isn’t just data — it’s the entire data factory.

To help address this, NVIDIA introduced at GTC its Physical AI Data Factory Blueprint, an open reference architecture that transforms compute into large-scale, high-quality training data. Built on NVIDIA Cosmos open world foundation models and the NVIDIA OSMO operator, it unifies data curation, augmentation and evaluation into a single pipeline, enabling developers to generate diverse, long-tail datasets from limited real-world inputs.

Leading physical AI developers including FieldAI, Hexagon Robotics, Linker Vision, Milestone Systems, Skild AI and Teradyne Robotics are already tapping the blueprint to speed up robotics projects, vision AI agents and autonomous vehicle programs.

Microsoft Azure and Nebius are the first cloud platforms to offer the blueprint, turning world-scale compute into turnkey data production engines.

“Together with cloud leaders, we’re providing a new kind of agentic engine that transforms compute into the high-quality data required to bring the next generation of autonomous systems and robots to life,” said Rev Lebaredian, vice president of Omniverse and simulation technologies at NVIDIA, in this press release. “In this new era, compute is data.”

From OpenUSD to Reality: Seamless Design to Deployment

Converting CAD files to OpenUSD is a critical step in the physical AI pipeline — transforming engineering data into simulation-ready assets that developers can use to build, test and validate robots in physically accurate virtual environments. 

Using tools like the NVIDIA Omniverse Kit software development kit and NVIDIA Isaac Sim, teams can optimize and enrich 3D data for real-time rendering, simulation and collaborative workflows.  

Companies including FANUC and Fauna Robotics are using this seamless CAD-to-OpenUSD workflow to speed up robotic system design and validation.

Transforming Manufacturing and Logistics Through Industrial Digital Twins

“Factories themselves are now robotic systems,” Lebaredian said during his special address on digital twins and simulation at GTC. 

All factories are born in simulation. The NVIDIA Mega Omniverse Blueprint provides enterprises with a reference architecture to design, test and optimize robot fleets and AI agents in a physically accurate facility digital twin before a single robot is deployed on the floor. 

KION, working with Accenture and Siemens, is using this blueprint to build large-scale warehouse digital twins that train and test fleets of NVIDIA Jetson-based autonomous forklifts for GXO, the world’s largest pure-play contract logistics provider. 

Physical AI Steps From Simulation to the Real World

NVIDIA is partnering with the global robotics ecosystem — including leading robot brain developers, industrial robot giants and humanoid pioneers — to enhance production-level physical AI. 

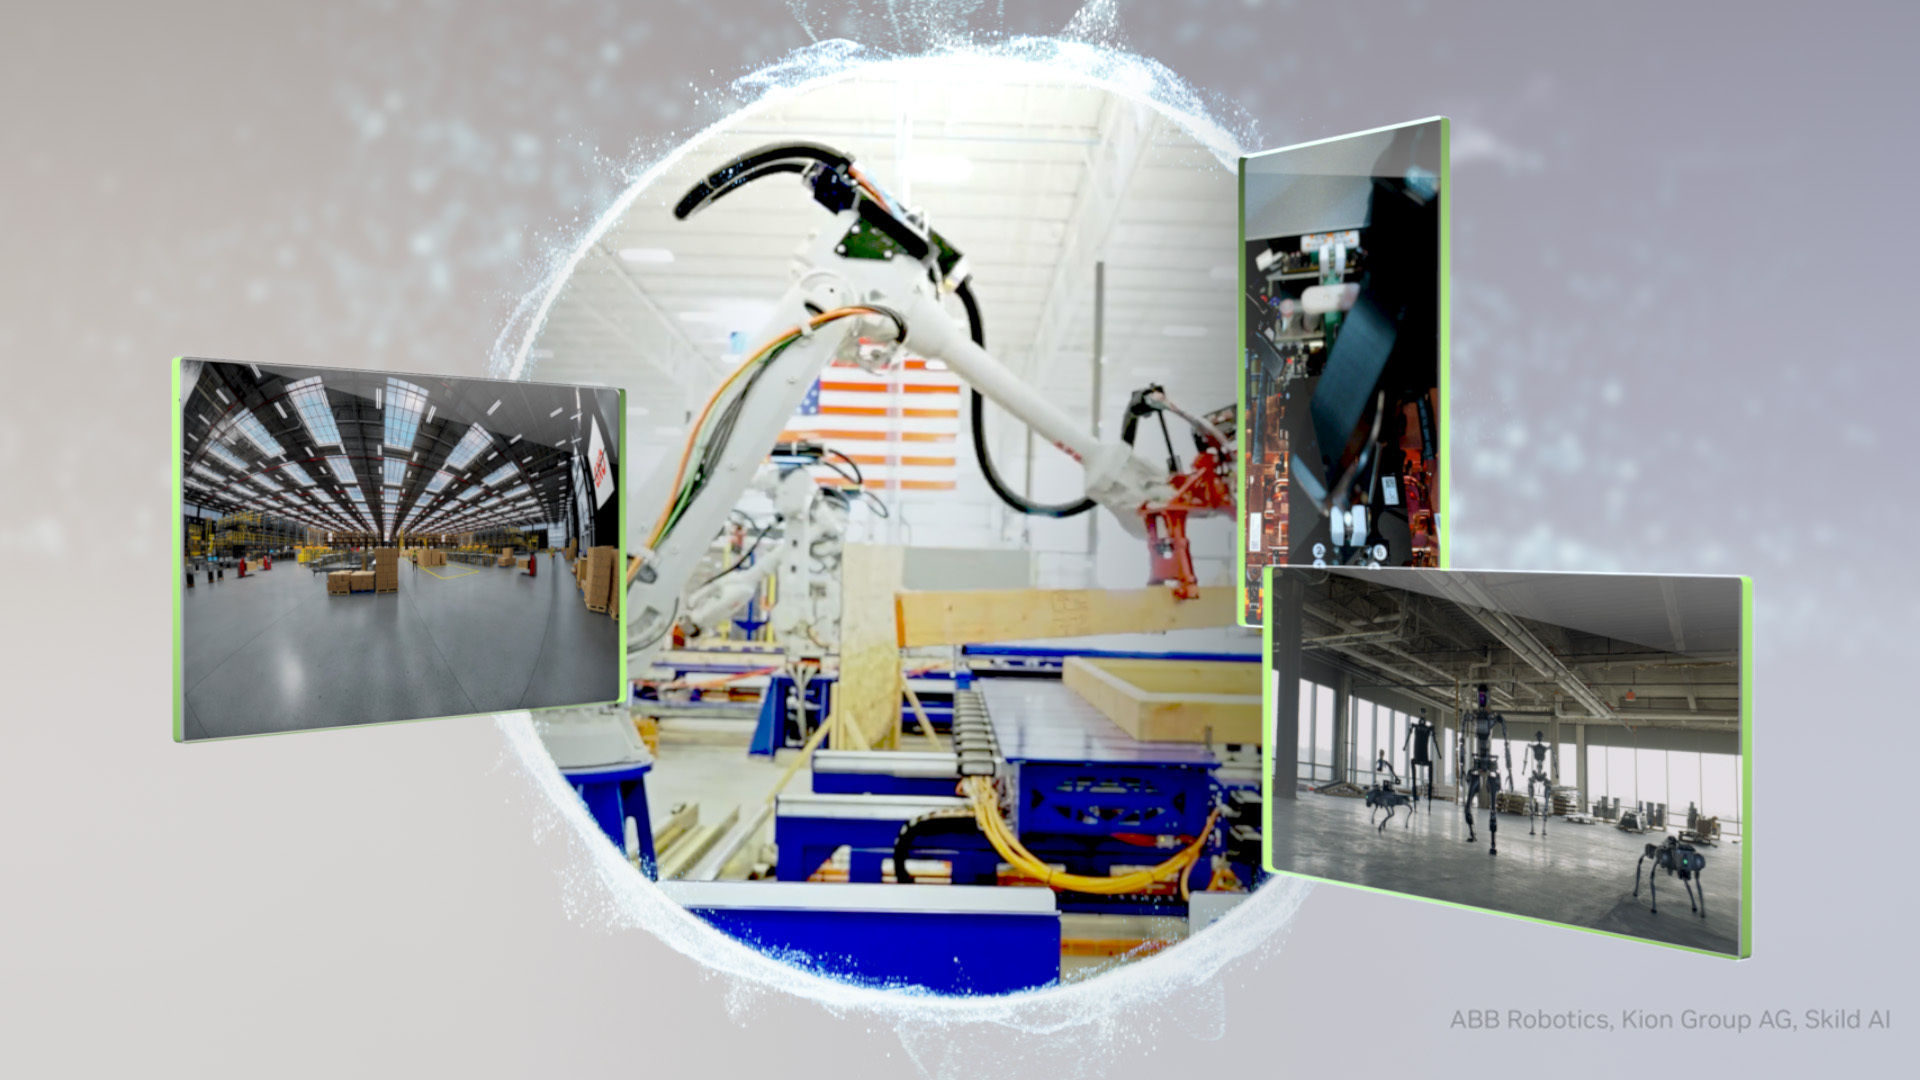
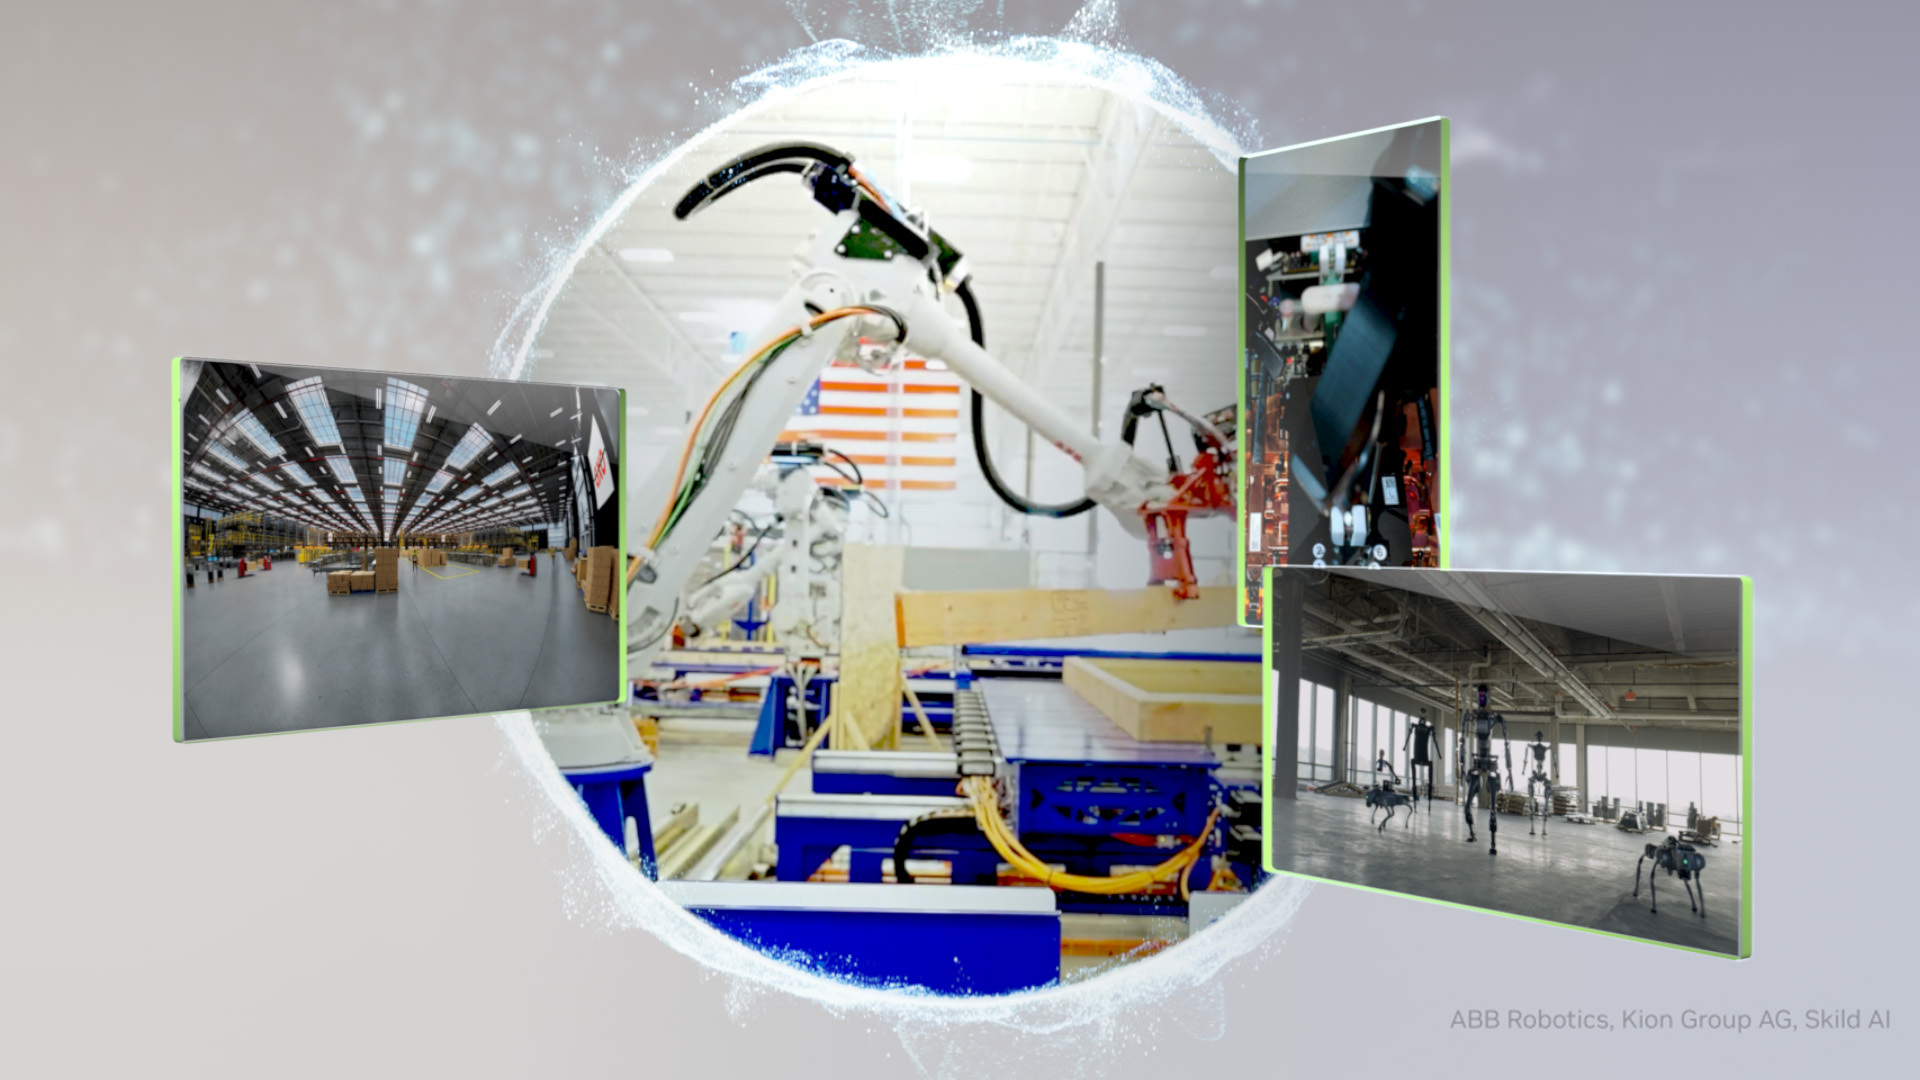
ABB Robotics, FANUC, KUKA and Yaskawa, which have a combined global install base of over 2 million robots, are using NVIDIA Omniverse libraries and NVIDIA Isaac simulation frameworks to validate complex robot applications and production lines through physically accurate digital twins. These companies have also integrated NVIDIA Jetson modules into their controllers to enable real-time AI inference. 

Robot development starts with the robot brains, which is why leading developers including FieldAI and Skild AI are building theirs using NVIDIA Cosmos world models for data generation and Isaac simulation frameworks to validate policies in simulation. 

Meanwhile, Generalist AI is using NVIDIA Cosmos to explore generating synthetic data. This combination allows robots to become proficient in any task — from supply chain monitoring to food delivery — at an exceptional pace. 

Read all of NVIDIA’s announcements from GTC on this online press kit and watch the keynote replay. Catch up on all Physical AI Days sessions from GTC and watch the developer livestream replay.