Skild AI Taps NVIDIA Physical AI to Teach Robots New Tasks From a Single Video


Manufacturing floors, warehouses and production lines rarely stay fixed — tasks change, layouts shift and new products arrive, and most robots can’t keep up without significant reprogramming.

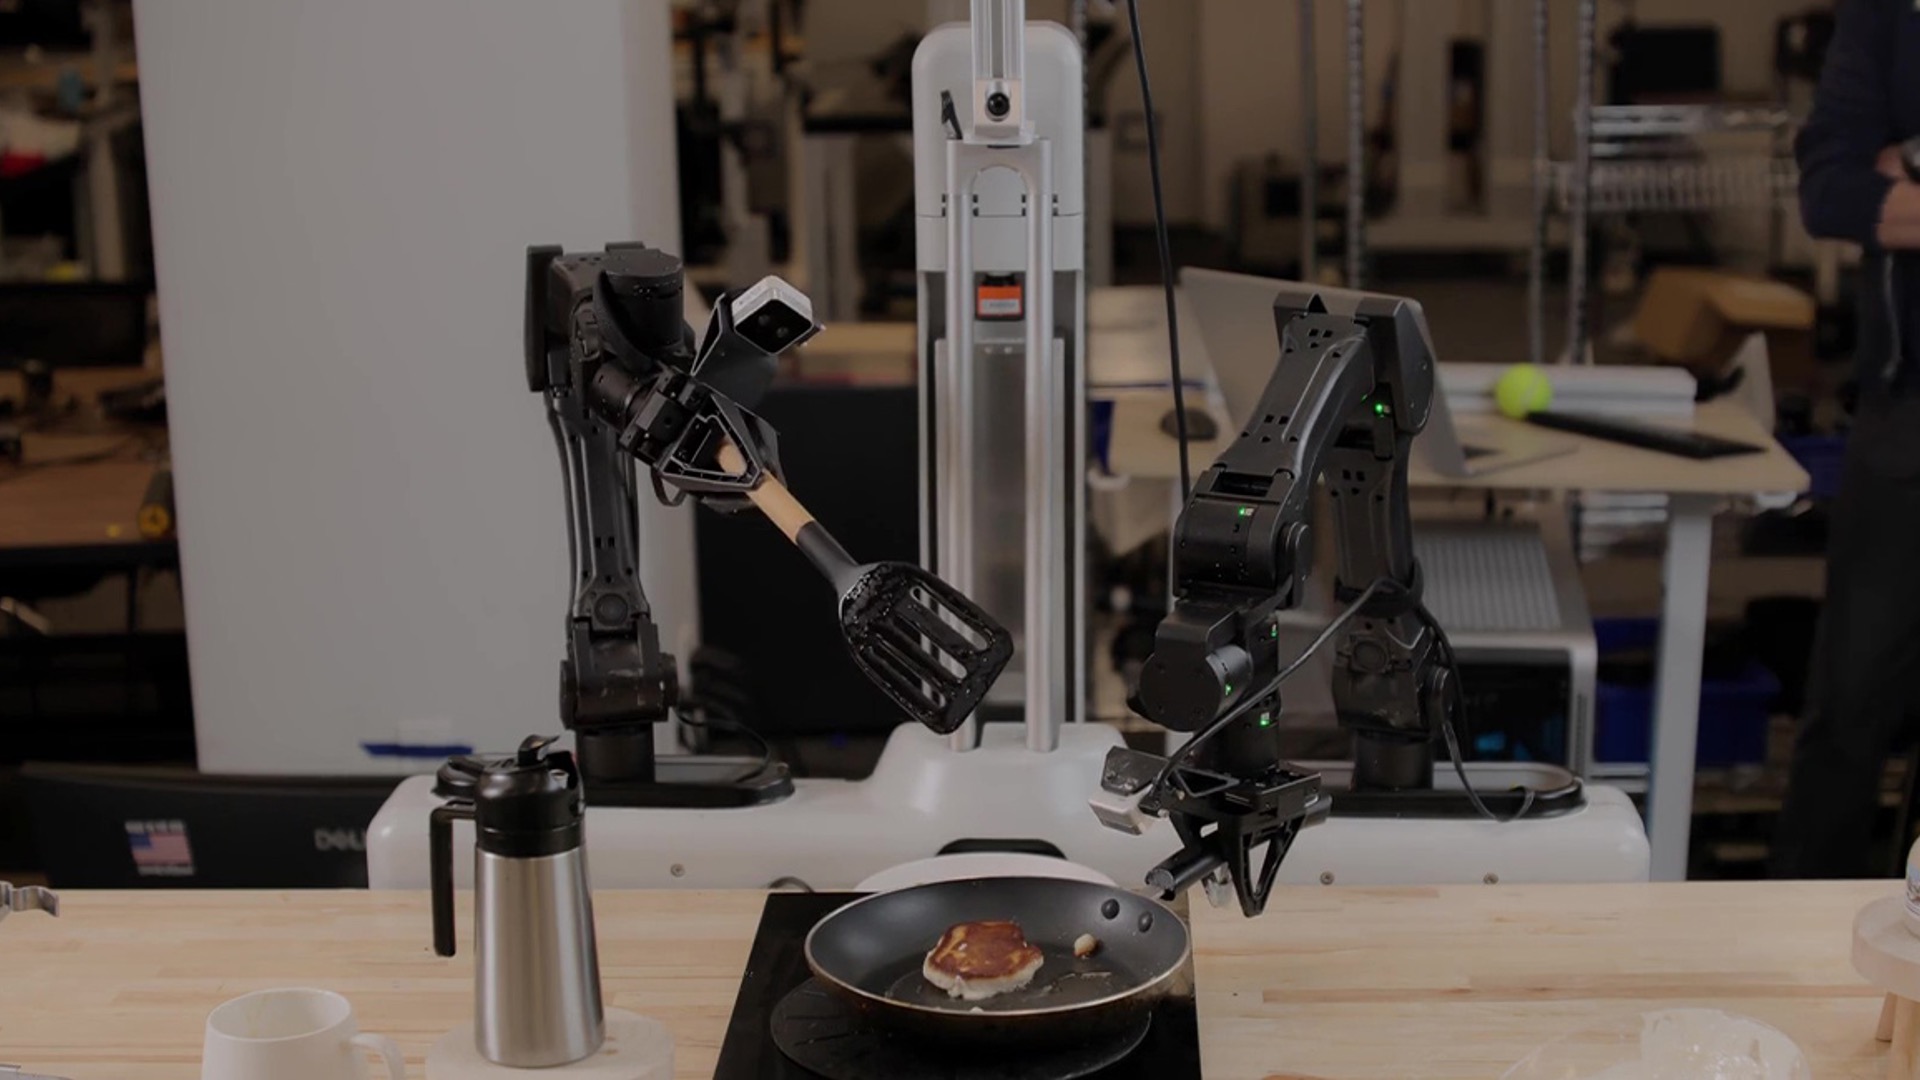
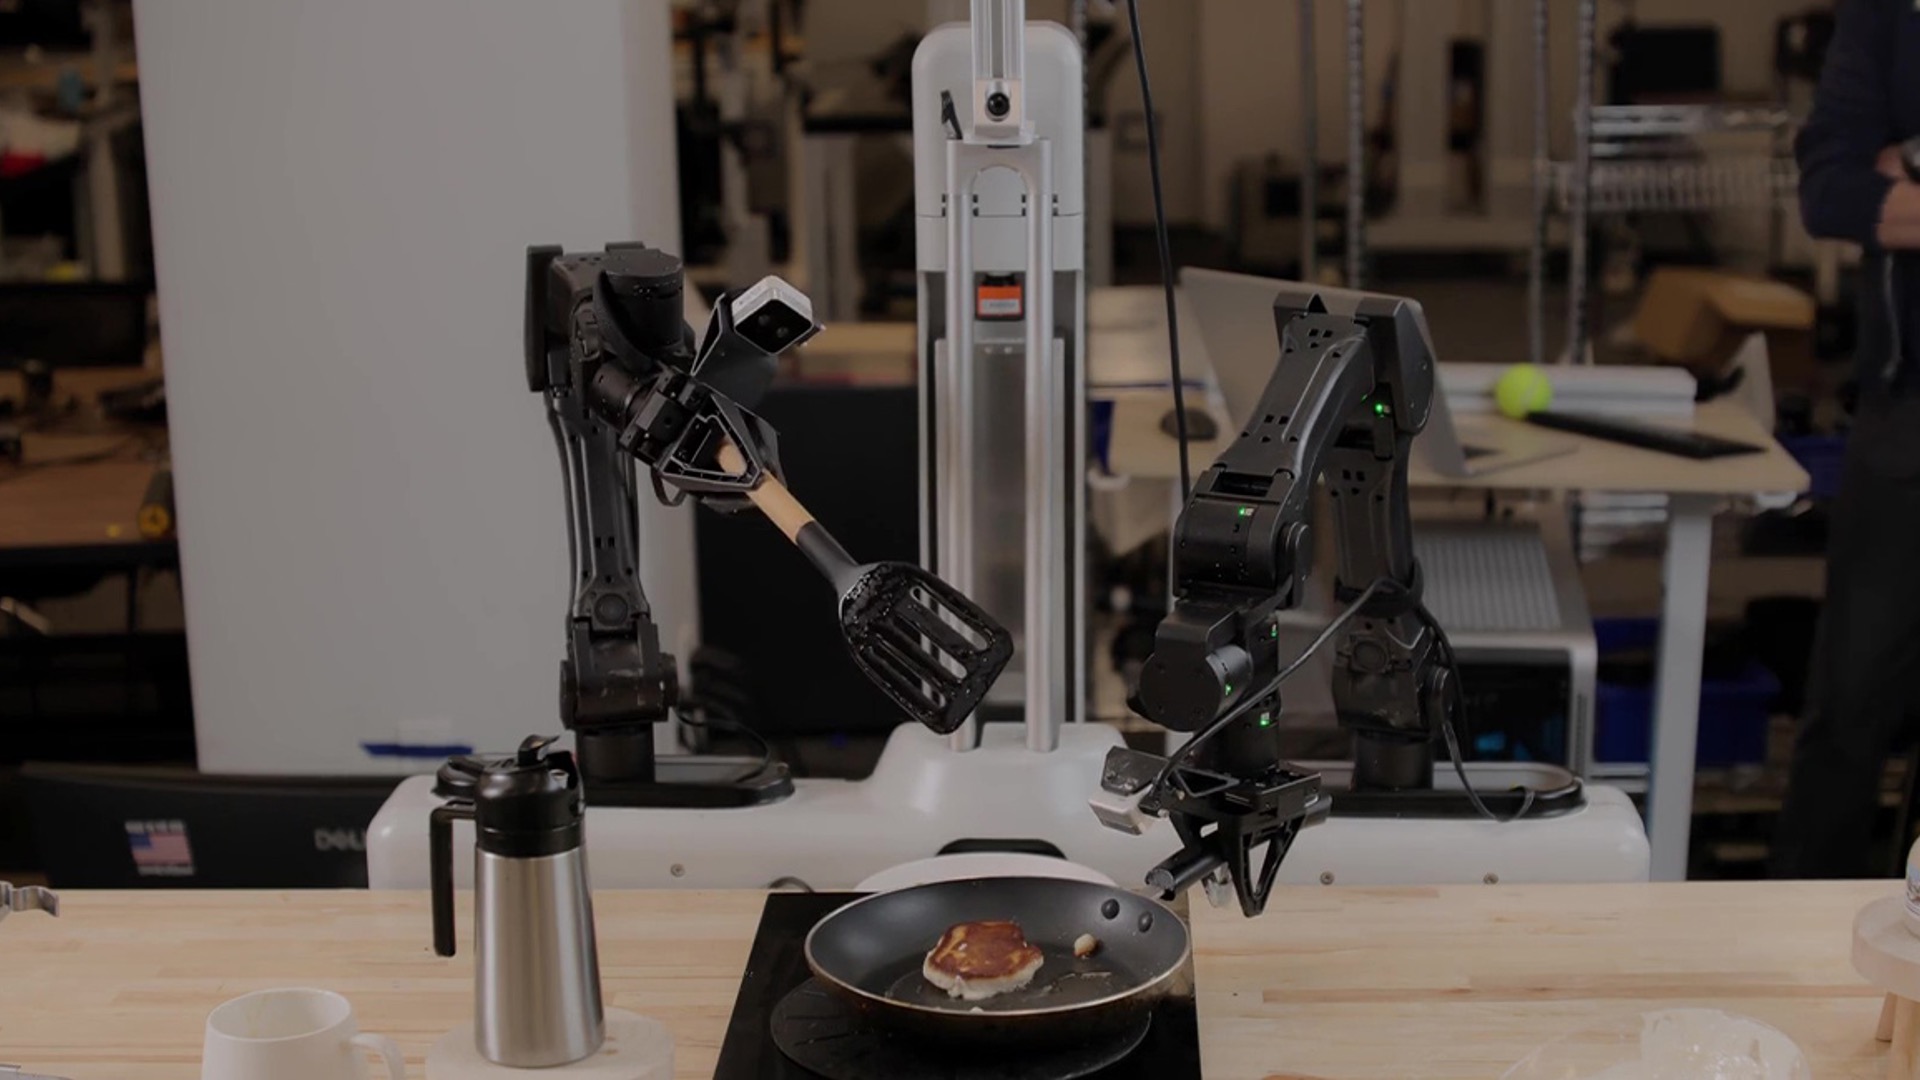
Skild AI’s new S1 robot foundation model helps address this, designed to learn previously unseen, long-horizon tasks from a single video demonstration. The model, launched last week, uses video as input to understand and execute the task without updating its weights or undergoing task-specific post-training — a technique called in-context learning.  

Skild built S1 and conducted the research on NVIDIA AI infrastructure, part of a broader collaboration spanning synthetic data generation, model training, simulation and real-world physical AI deployment. The companies are working together to move adaptable robot intelligence from the lab into factories and other dynamic operating environments.

“Learning by experience, and not preprogramming, is the step change that has happened in robotics,” said Deepak Pathak, cofounder and CEO of Skild AI. “NVIDIA Isaac Lab and NVIDIA Cosmos technologies help Skild create the scalable, diverse experience its robots need to learn across many scenarios and embodiments.”

The launch comes as the company reached a $100 million annual revenue run rate 10 months after its first commercial deployment. In that time, Skild has built more than 60 deployment partnerships with work spanning manufacturing, logistics, inspection, security, food preparation and other applications. 

Learning New Work From One Video

Most industrial robots are built for fixed jobs, so each new product, process or layout requires more data, retraining and validation.

S1 takes a different approach: An operator records a video of the desired task and provides it to the model as a prompt. It interprets the demonstrated intent, objects and sequence, then maps them into actions for the robot in front of it — with no retraining — and often for a task not covered by its pretraining dataset. 

S1 can perform unfamiliar tasks lasting up to 10 minutes, including plant potting, pancake making, pour-over coffee brewing and kit assembly. These tasks can span dozens of manipulation steps and require the robot to compose skills in sequences it hasn’t previously performed. 


In one plant-potting test, the Skild AI team moved from recording the demonstration to autonomous execution on hardware in just 11 minutes. The model can also adjust when objects move, recover from errors and combine skills in sequences that weren’t explicitly programmed.

In Skild’s tests on new, multistep tasks, its S1 robot succeeded about 66% of the time at each step, compared with 9% for a similar AI system — a more than sevenfold improvement. Skild also estimates that showing the robot one short video example can be as useful as giving it roughly 380 hands-on training examples. A person collecting those examples manually could take 50-100 hours.

From Research to Factory Work

S1 breaks the cycle of needing to constantly retrain robots for new factors by letting operators demonstrate new tasks directly without requiring a new dataset or training run for every change. Where customer agreements permit, experience from Skild’s commercial deployments can inform the broader model and help accelerate future deployments.

That work is already in action on the factory floor. Skild, NVIDIA and Foxconn are deploying the Skild Brain on dual-arm manipulators for high-precision assembly of NVIDIA Blackwell systems. In one demonstrated workflow, a robot installs a busbar and limit block, fastens 16 screws and adapts to disturbances across a multistep task. The work requires precise motion, contact-aware control, sequence tracking and recovery when the scene differs from the plan.


NVIDIA Technology Across the Development Cycle

NVIDIA accelerated computing gives Skild the scale to train its shared robot brain using simulation, human video, teleoperation and, where permitted, deployment data. NVIDIA Cosmos open world foundation models help diversify training data and turn video into structured descriptions, while Cosmos Curator helps annotate, filter and organize data at scale.

Skild is extensively using NVIDIA’s open simulation frameworks to train and validate its robot brain before real-world deployment. NVIDIA Omniverse libraries and the NVIDIA Isaac Sim framework provide physically based virtual environments for generating data, testing edge cases and validating behaviors.

Skild further strengthens the skills of its brain through reinforcement learning in Isaac Lab, an open modular robot learning framework. Powered by the Newton physics engine, Isaac Lab helps Skild’s engineers accurately model various physical parameters, such as forces, contact, collision and pressure, and reduce the simulation-to-reality gap.

Skild and NVIDIA are also jointly developing new GPU-accelerated simulation solvers that quickly and accurately model how robots physically touch, grip and manipulate solid objects. They’ll soon be made available to all developers as part of Newton. 

As models move toward production, NVIDIA Nsight tools help engineers find performance bottlenecks during training, and the NVIDIA TensorRT software development kit optimizes inference so robots can respond quickly in the physical world. Together, these technologies connect the data, simulation, training and deployment stages instead of treating them as separate systems.

Read Skild AI’s S1 research and explore the NVIDIA Isaac robotics platform.
Build AI Anywhere With NVIDIA Jetson


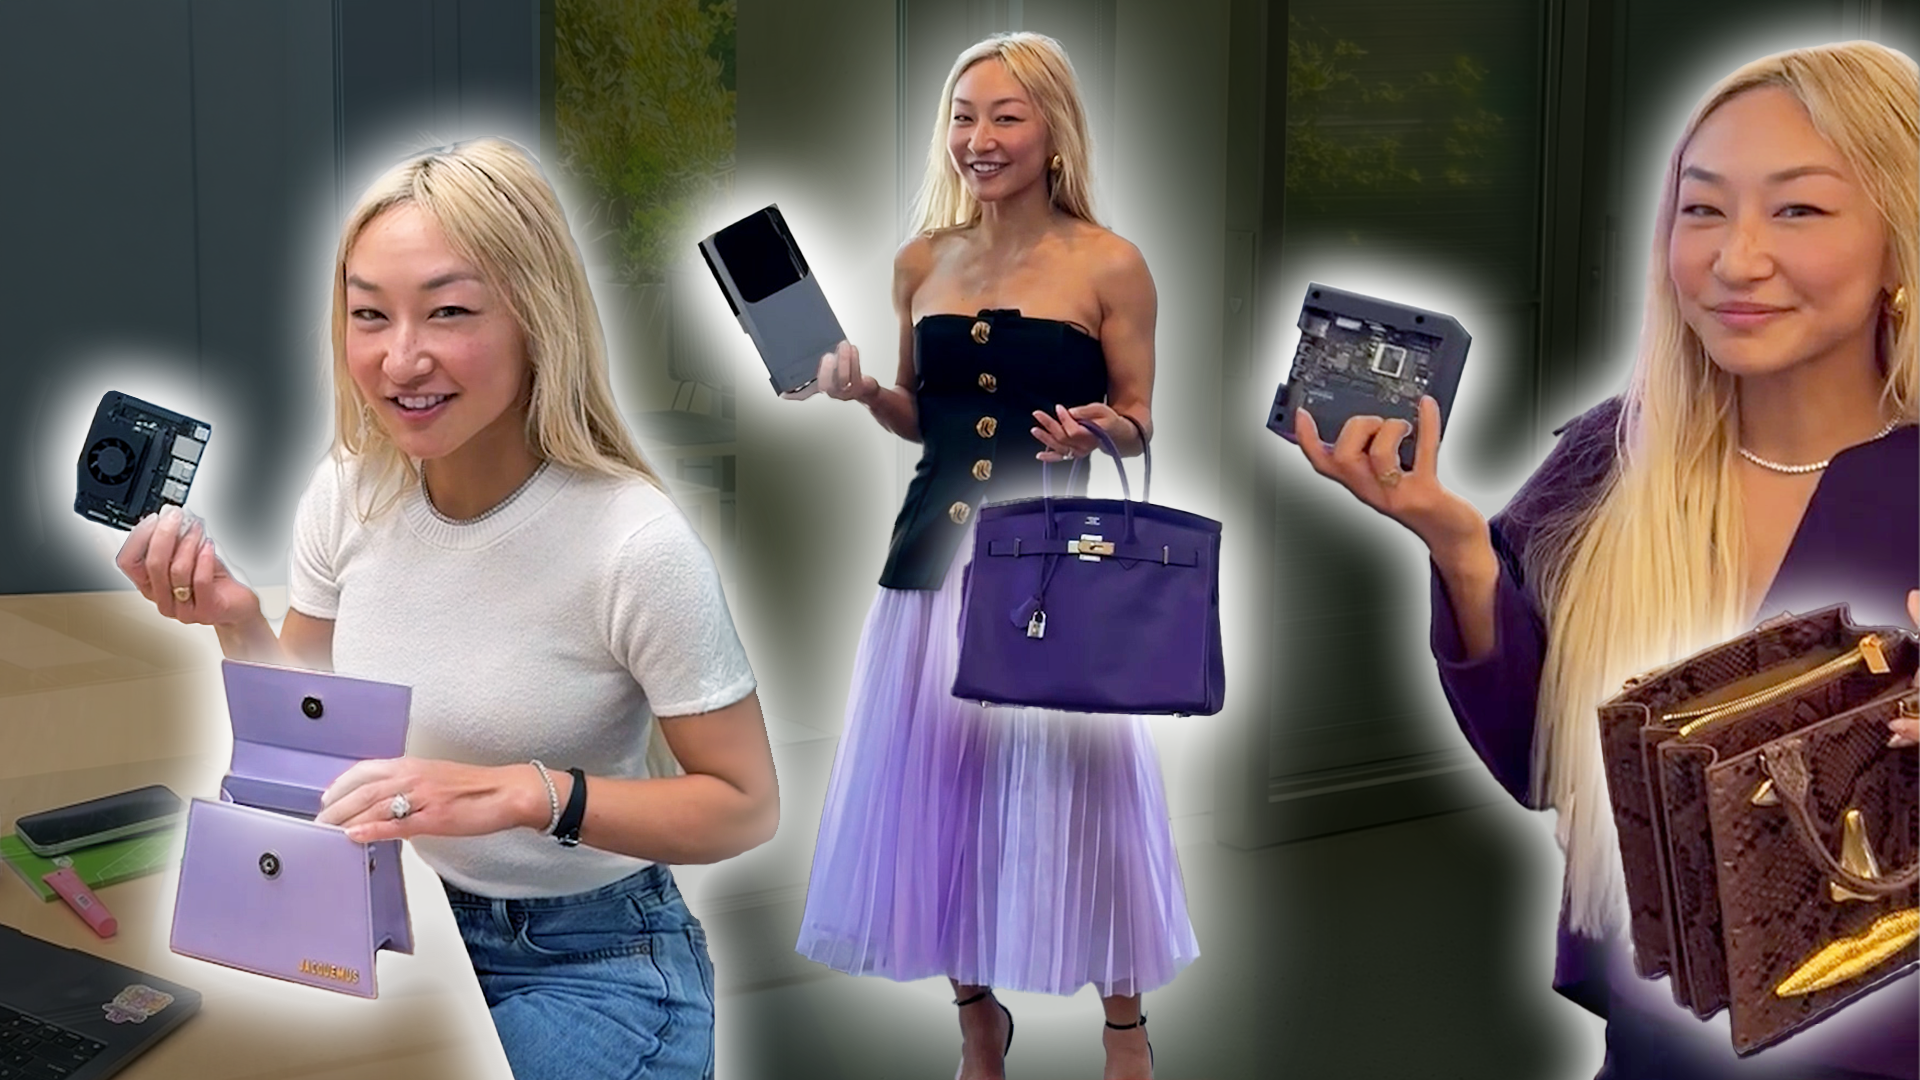
As a discerning AI investor who values style and substance, Sarah Guo knows this season’s standout accessory isn’t the latest designer purse — but what’s inside it. 

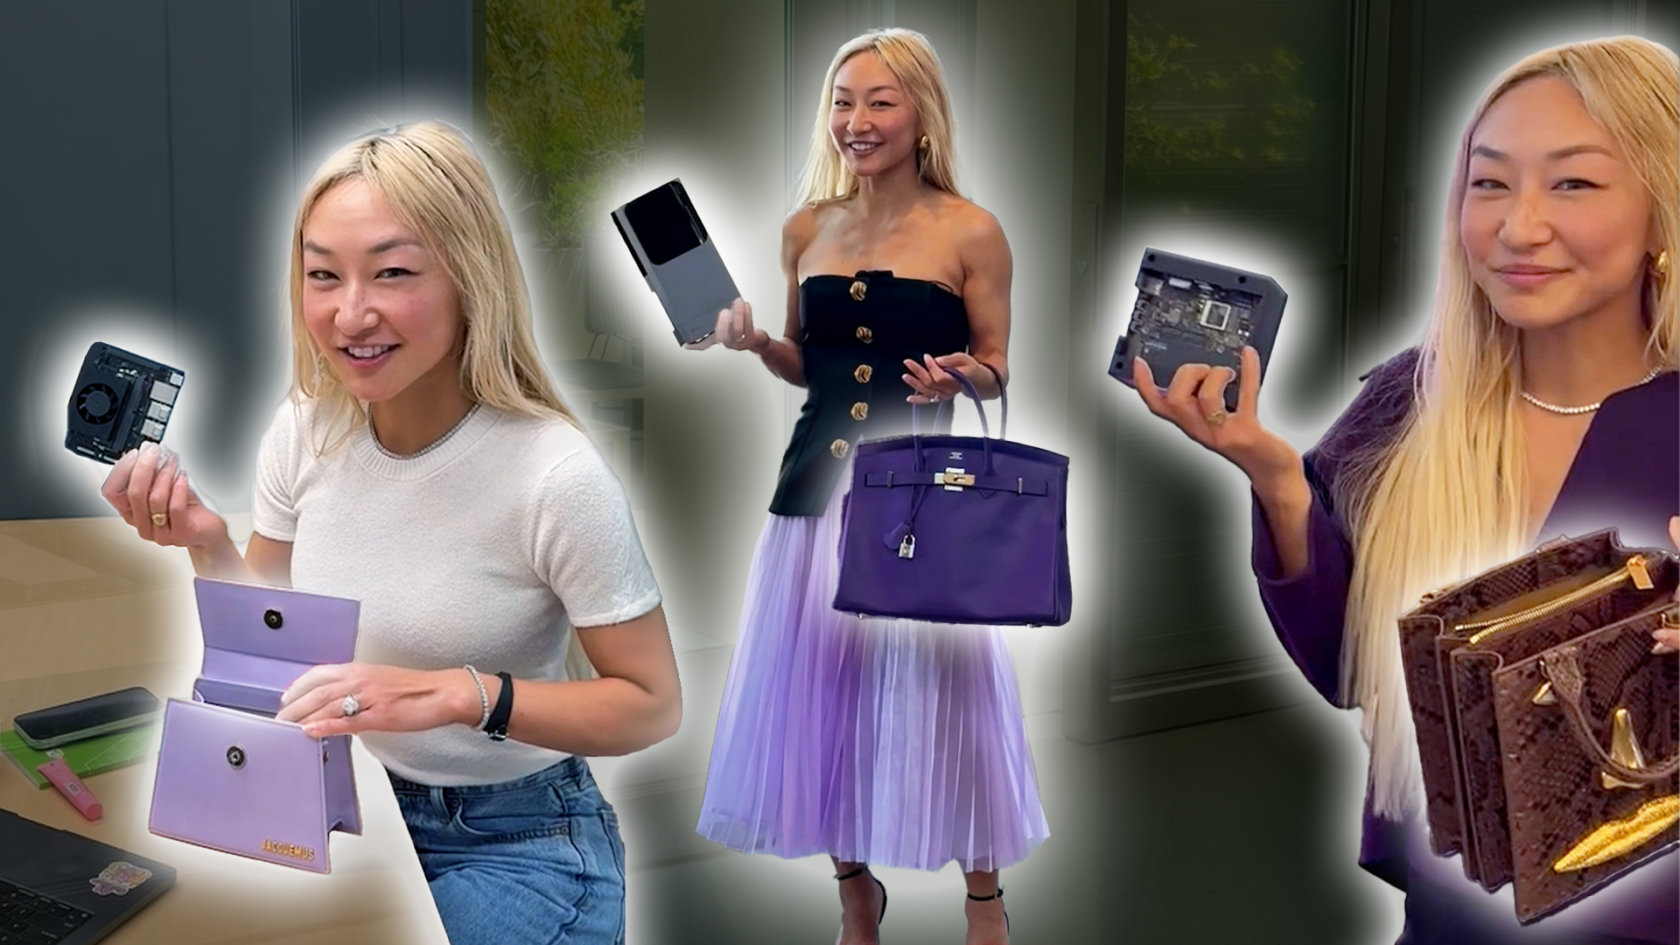
In a recent video, Guo, founder of AI-native venture capital firm Conviction and co-host of the AI podcast No Priors, highlighted how the NVIDIA Jetson platform for edge AI and robotics gives busy developers both power and portability in one agentic-ready AI platform built for the physical world — and every industry. The best part? It all fits in one handbag.

Compact enough to carry in a bag, yet powerful enough to take on the toughest problems, NVIDIA Jetson modules and developer kits power robots, autonomous machines and real-world AI projects in classrooms, labs and makerspaces — wherever inspiration strikes — enabling developers to build using industry-transforming frontier open models at the highest standard of safety and security.

Whether for a student running their first robotics project on Jetson Orin Nano Super, a professor bringing cutting-edge AI to their curriculum on Jetson AGX Orin or a researcher pushing the limits of autonomous systems with Jetson AGX Thor, the platform enables building, learning and launching the next generation of intelligent robots — in every classroom, every lab and every country. 

As Guo shows: bring the bag, Jetson brings the robot brain. 

Check back here throughout the week for a series of examples — beginning with the Jetson Orin Nano Super below — to help developers navigate the NVIDIA Jetson platform and get started on their next robotics breakthroughs.

NVIDIA Jetson Orin Nano Super: Ideal for Building a First AI Robot

Robots deserve a real brain and, apparently, an incredibly chic commute. When Guo popped the Jetson Orin Nano Super into her Jacquemus Mini, she gained the entire AI stack right at her fingertips — now with a cute handle: clutch!

Jetson Orin Nano Super brings desktop-class generative AI to a handbag-friendly developer kit, offering first-time builders a practical path to learning computer vision, building AI agents, prototyping edge AI and more. With 67 trillion operations per second (TOPS) of AI performance, Jetson Orin Nano Super helps developers get started on the problems they’ve always wanted to solve.

To help builders move from inspiration to implementation, NVIDIA Jetson Device Skills and Jetson BSP Skills give students, researchers and developers an easier way to harness coding AI agents to create, optimize and deploy real-world AI at the edge.

Robot builders can get inspired to start their first — or next — dream project with these innovative examples of Jetson Orin Nano Super in action:

Self Driving My EV Car  | Model SidewalkPilot

A custom SidewalkPilot AI model autonomously executes maneuvers in a toy electric vehicle using Jetson Orin Nano Super.

Reachy Mini Jetson Assistant

Reachy Mini Jetson Assistant is a low-latency, fully on-device voice and vision assistant for Reachy Mini Lite powered by NVIDIA Jetson Orin Nano Super. Everything runs locally with GPU acceleration — no cloud, no API keys, no internet required at runtime. Get started here.

Building My First AI Robot From Scratch

Coding with Lewis constructed an AI-powered robot using Mistral — an open-weight model — showing that first time robotics developers can build from the ground up using Jetson Orin Nano Super.

Robotics AI Podcast

Using Jetson Orin Nano Super, Asier Arnaz built a Yocto-powered Robotics AI video podcast featuring two AI models discussing topics in real-time and highlighting what makers are creating at the edge.

Inspired yet? Get started by joining our livestream series. Across three modules, developers can learn to run generative AI, build claw agents and bring vision-language and vision-language-action models to power real-world physical AI applications — all on NVIDIA Jetson.

Bring Powerful AI to Real-World Machines With Jetson AGX Orin

With 275 TOPS of AI performance, Jetson AGX Orin is there when workloads get more complex. For Guo, it’s simple: more TOPS, more tote.


For more advanced makers, Jetson AGX Orin brings the full power of AI into coursework, capstone projects and applied research, powering advanced robots, autonomous machines and AI at the edge — and proving serious AI no longer has to live in a server room, or be reserved for those who can afford one. 

Jetson AGX Orin lets builders test real ideas in real environments, then carry the whole thing to class, the lab, the demo table or that first investor meeting.


With versatility for advanced robotics curriculum and serious startup projects, Jetson AGX Orin can support computer vision, generative AI, autonomous navigation and more, making it ideal for transforming virtually every industry, whether creating delivery bots, smart vision capabilities or industrial automation.


Go next-level with these innovative examples of Jetson AGX Orin in action:

Live VLM WebUI

A browser-based interface streams live vision language model inference on Jetson AGX Orin, letting users interact with a VLM in real time through their camera feed.

SMoRes

A Carnegie Mellon University robotics team’s autonomous system builds a 3D map of an environment while simultaneously searching for survivors in time-critical rescue scenarios.

Tomorrow, build bigger than ‘back to school’ with Jetson AGX Thor.

NVIDIA Open Sources First GPU-Accelerated Medical Physics Simulation Framework


Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. And the rare, edge scenarios developers most need to understand don’t appear on schedule.

That creates one of the biggest bottlenecks in healthcare robotics: obtaining the enormous amount of varied data developers need to train, test and improve robot behavior.  

NVIDIA Medical Physics Simulation framework — a new open source, GPU-accelerated capability within NVIDIA Isaac for Healthcare — announced today, helps medical robotics developers model anatomy-device interaction, generate hard-to-capture scenarios, test in silico, and train or evaluate robot policies before hardware-heavy testing. 

The framework brings together anatomy and medical device behavior with sensor simulation and robot learning so teams can create reusable simulation environments instead of rebuilding custom scenes for every workflow, saving developers time and bringing innovations to market faster. 

Because Medical Physics Simulation is open source, healthcare robotics developers can inspect the framework, adapt it to their own devices and workflows, and build on a GPU-accelerated foundation that works seamlessly with the broader NVIDIA stack.

Open source is especially important in healthcare because teams need transparency into the data, models and weights that shape system behavior. Access to open models and model weights can help developers reproduce results, evaluate performance across different anatomies and scenarios, identify limitations and build evidence for regulatory review. 

A Virtual Training Ground for Medical Robots

For physical AI, experience is data in motion. Developers need to train robots to operate properly even when anatomy changes, devices behave differently, conditions shift or a policy fails unexpectedly.

Medical Physics Simulation helps developers simulate anatomy, device contact, friction and sensor inputs, then test in interactions and environments to evaluate how robots perform across those changes. Powered by NVIDIA CUDA and part of Isaac for Healthcare — built on the NVIDIA Warp, Newton and Cosmos simulation and generative AI technologies — the framework can run hundreds of parallel simulation environments, helping teams explore more scenarios and identify failure modes earlier in development. 

For robot builders, this turns simulation from a bespoke engineering project into reusable infrastructure. The difference now is scale: benchmarks show 8,192 robot-training environments running in parallel with GPU-native simulation cut training from over five hours to under two minutes. 

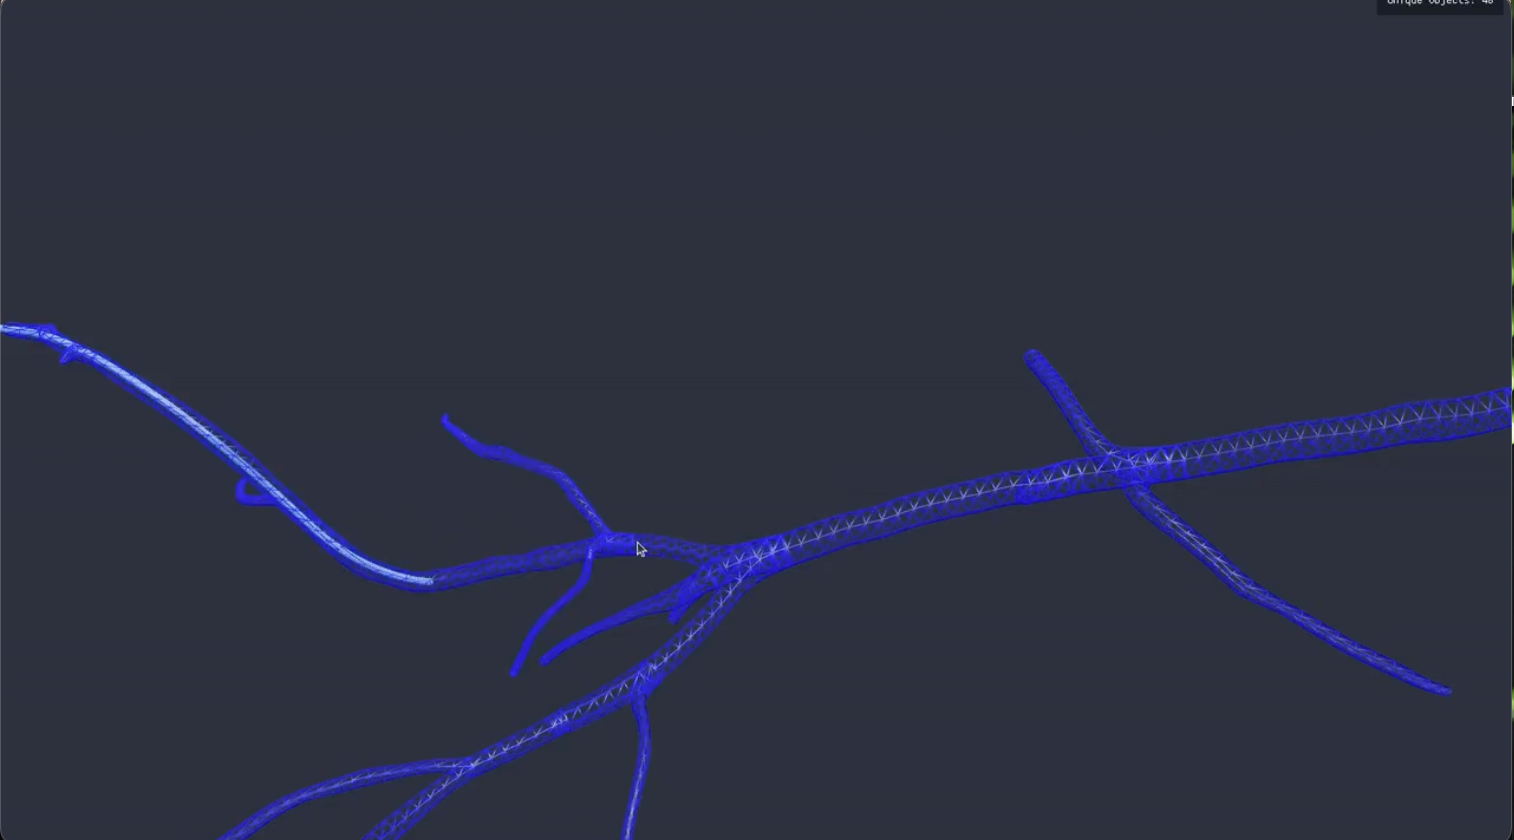
With this framework, developers can connect vascular anatomy, flexible instruments such as catheters and guidewires, simulated X-ray imaging and reinforcement learning. The framework is designed to extend beyond that example to additional devices, anatomies, sensors and healthcare robotics domains.

Medical Physics Simulation brings together classical physics simulation and generative AI physics simulation. Classical simulation helps model known physical rules, such as device contact, friction and motion. NVIDIA Cosmos-H Dreams, the real-time generative AI physics simulation capability within Medical Physics Simulation, helps model visual scene dynamics learned from procedural data.

Together, these approaches give developers a richer way to build and test healthcare robotics systems in virtual environments before moving to physical prototypes and lab testing.

An Ecosystem Building the Future of Medical Robotics

Medical robotics leaders are already applying simulation-driven development to solve specific surgical challenges.

CMR Surgical and Cambridge Consultants, part of Capgemini, are using Cosmos-H-Dreams to implicitly learn interaction physics for soft-tissue surgical procedures and generate patient-specific simulations. CMR contributed nearly 500 hours of anonymized clinical data from its Versius Surgical Robotic System to the Open-H Embodiment open dataset, benefiting procedures including cholecystectomy, prostatectomy, hernia repair and hysterectomy.

“Open source models allow us to build on shared knowledge, accelerating responsible innovation and, ultimately, gives us the potential to deliver more consistent care and better outcomes for patients worldwide,” said Chris Fryer, chief technology officer at CMR Surgical.

Johnson & Johnson MedTech is using Isaac for Healthcare’s Medical Physics Simulation and a Cosmos-based foundation model to build digital twins of its endoluminal MONARCH platform for urology, modeling complex anatomy and kidney-stone scenarios.

XCath is using the Medical Physics Simulation for endovascular autonomy policy training. Inner Logic is accelerating the evolution of medical technology with synthetic data, validating device mechanics and producing in silico evidence to support regulatory pathways with NVIDIA Medical Physical Simulation.

Medtronic Structural Heart is exploring applying Medical Physics Simulation with simulated X-ray sensing to generate data for catheter navigation research.

A New Layer in the Isaac for Healthcare Stack

As a modular capability within NVIDIA Isaac for Healthcare, Medical Physics Simulation can be used on its own or alongside digital twin pipelines, medical sensor simulation, the NVIDIA Isaac Lab open robot-learning framework and NVIDIA open models and policies.

Developers can explore the open source Medical Physics Simulation framework, review available reference workflows and start building simulation environments for their own devices, anatomies and healthcare robotics applications.

NVIDIA Research Advances Robotics From Simulation to the Real World


Robotics is entering a new phase: moving from controlled demos and scripted automation toward generalizable, reliable embodied autonomy in the real world. 

At the International Conference on Robotics and Automation (ICRA), eight of NVIDIA Research’s 28 accepted papers show how simulation-to-real transfer is becoming a foundation for that shift, helping robots perceive, reason, plan and act across dynamic, unpredictable environments.

Together, the papers span the full stack of challenges robot developers face: coordinating multiple arms in parallel, building policies that generalize across robot bodies, grasping novel objects in clutter, performing precise assembly and developing vision-language-action models that reason before they move. 

The throughline is clear: sim-to-real is becoming a foundation for robots that can adapt, generalize, and operate with greater reliability outside the lab.

Coordinating Arms, Navigating Bodies, Grasping Objects

Picture a pharmaceutical lab run by robotic arms: picking up tubes, transferring liquids, mixing reagents — each step taking different amounts of time, all requiring careful coordination. 

Traditional robot scheduling software handles those steps sequentially, one arm at a time. 

ScheduleStream changes that by running computations on GPUs, letting multiple arms plan movements and operate in parallel. The result — a 3x speedup across multi-arm planning scenarios, on hardware like the NVIDIA Jetson edge AI platform. Code for the framework is available on GitHub.


A robot that learns to navigate through a space — avoiding obstacles and finding its destination — usually learns to do it in one body. Put the same navigation software into a differently shaped robot and it often falls apart, because its parts all move differently. 

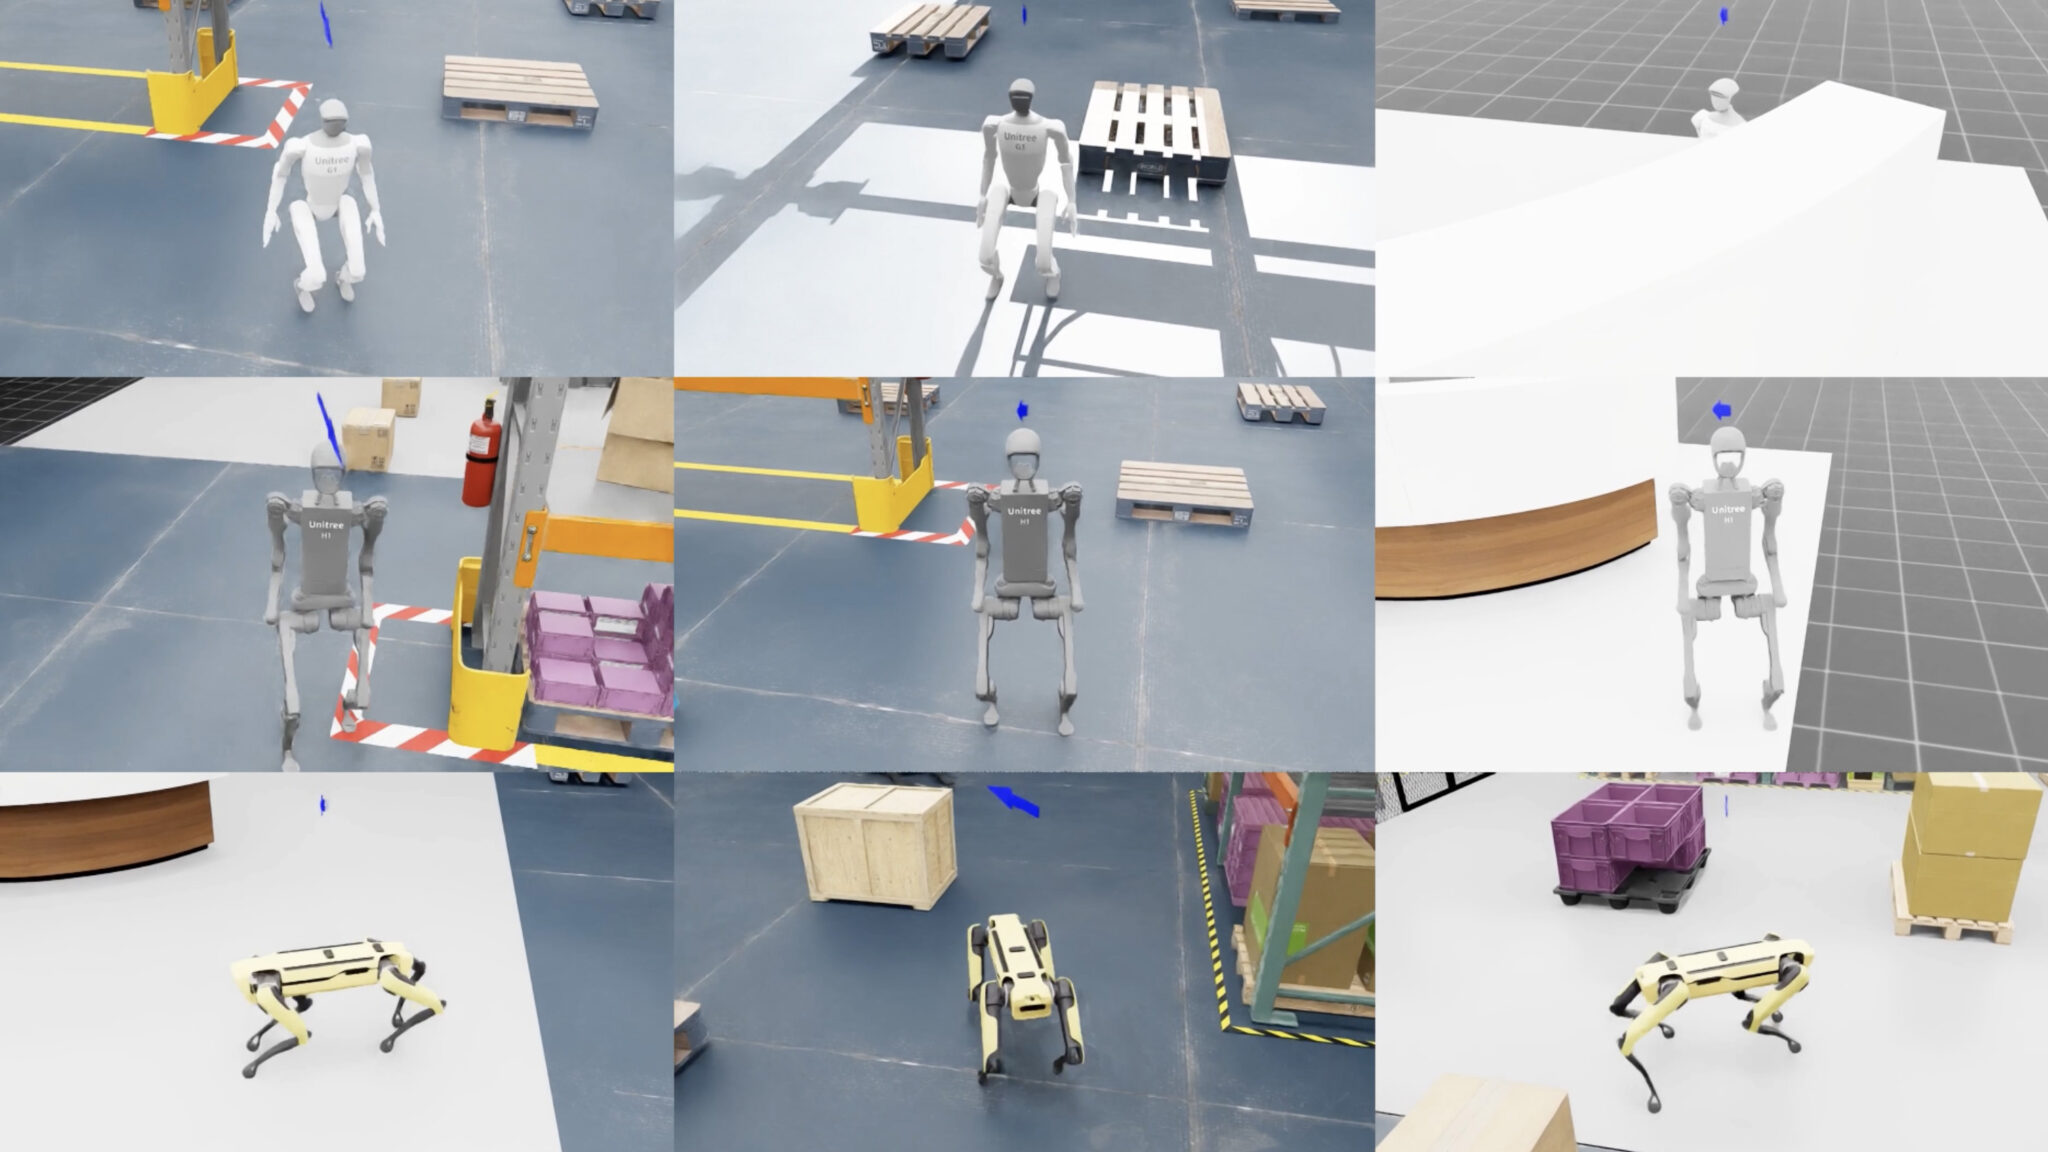
The COMPASS policy framework solves this by first building the baseline navigation functionality using imitation learning and then using residual reinforcement learning in NVIDIA Isaac Lab to build specialists for diverse robot embodiments. Crucially, no real-world robot data is involved at any stage: everything is trained in Isaac Lab simulation. 

Compared with an imitation learning baseline, COMPASS achieved a 4.5x improvement in average success rate. It also seamlessly transfers to real-world environments, demonstrating around 80% success across 20 real-world navigation trials on autonomous mobile robots and humanoids. 

COMPASS is agent-friendly, with dedicated skills — and developers can connect the pipeline with NVIDIA Omniverse NuRec to post-train and validate robots in a digital twin of a novel environment before deployment. 

Most grasping systems identify the object, predict a grasp, plan a path, then execute. But the last few centimeters are where small errors matter most.

Grasp-MPC adaptively computes robotic grasps, continuously correcting the robot’s motion as it closes in on the object, rather than carrying out a fixed plan — the way a person grabs something by feeling rather than calculating every joint angle in advance.

To build the policy, the researchers generated 2 million simulated trajectories across 8,000 objects using annotations from the GraspGen dataset and motion planning data from cuRobo, a CUDA-accelerated library for robot motion generation. 

After training on both successful and failed trajectories, Grasp-MPC learned to grasp novel objects in cluttered tabletops and shelves — achieving around 75% overall success on real robots, compared with a baseline of 41%.


Deformable Cluster Manipulation introduces a framework that tackles a parallel challenge: enabling systems to grasp not just one object, but a whole bundle of flexible, tangled material at once. 

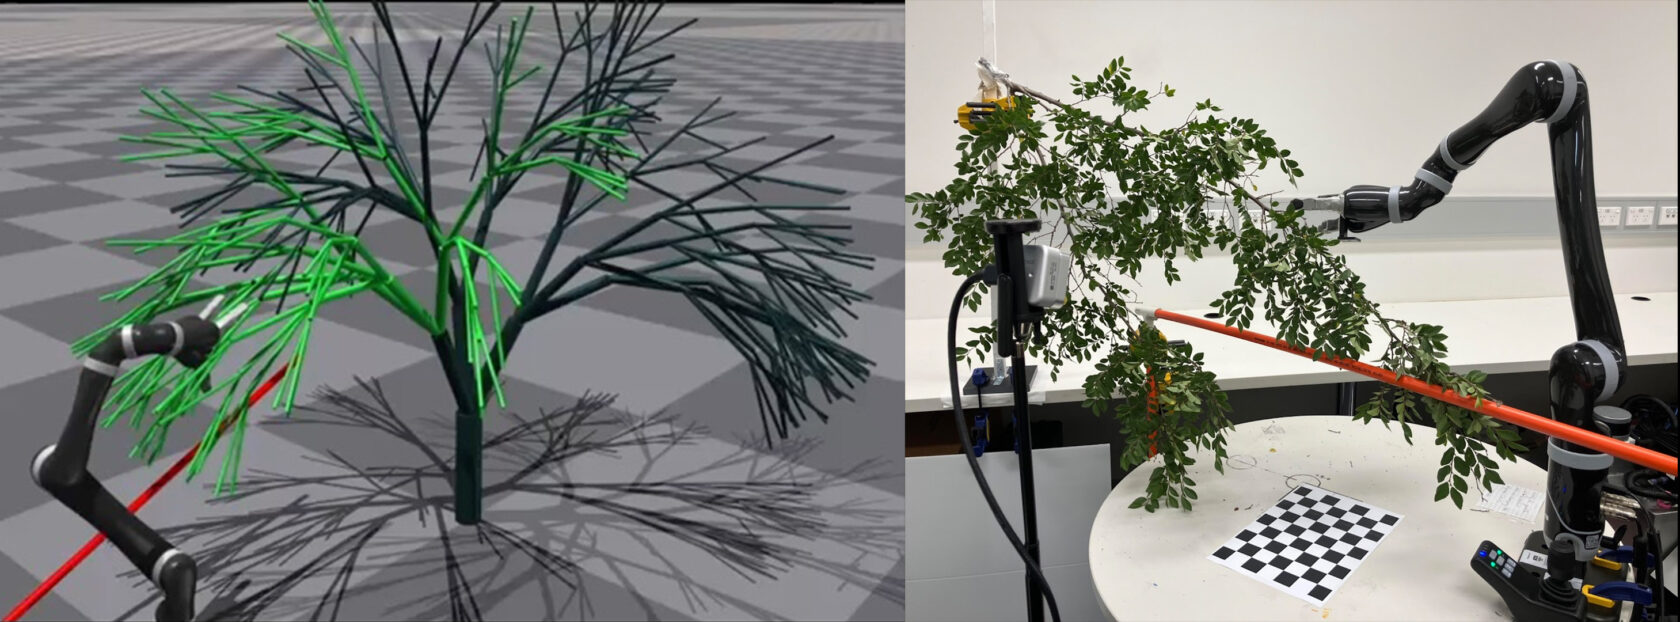
The framework was motivated by a real-world task: clearing a mass of tree branches that have grown over a power line, where there’s no single clean object to grab. The system uses its entire arm, not just the gripper: wrapping it around the branch cluster and sweeping it aside, the way someone might gather an armful of cables or push a tangle of brush out of the way. 

The researchers built a tree generator using biological growth equations to create synthetic trees of many different shapes and sizes — then trained the system across thousands of them in NVIDIA Isaac open simulation frameworks. 

The policy deploys to real branches zero shot. Beyond power lines, the researchers see potential in cable management, agricultural inspection and anywhere robots need to handle a tangle rather than a single graspable item.

Clearing tree branches in zero-shot sim-to-real deployment.

Assembling With Precision

Precise assembly — threading a nut onto a bolt, inserting a gear onto a gearshaft, pressing a peg into a hole — is notoriously hard to get right with simulation alone. 

The real world is complex. Real surfaces aren’t perfectly smooth. Sensors don’t behave as specified. Tiny discrepancies that a simulator ignores can stop a robot in its tracks.

The SPARR method addresses this by splitting the job in two. A policy trained in Isaac Lab learns the general strategy for the assembly task in simulation. Then, on the actual hardware, a second layer learns to correct for whatever the simulator got wrong — using the robot’s own camera and without any human demonstrations or guidance. 

SPARR improves success rates by 38% and reduces cycle time by around 30% compared with zero-shot sim-to-real baselines. 

On National Institute of Standards and Technology (NIST) assembly tasks not seen during training, success improves by nearly 75% — approaching the results of methods that require a human in the loop.

The Refinery framework takes on the next layer of difficulty in assembly: tasks with multiple sequential steps, where how step one is finished determines whether step two is even possible. It’s like assembling furniture — leave a panel at the wrong angle, and the next fastener won’t go in. 

By understanding how success varies across initial conditions and training across hundreds of simulated assembly scenarios, Refinery learns how to complete each step and leave each component in a position that sets up the next. It achieves 91% simulation success and a nearly 11% mean improvement over baselines with comparable real-world results — and its policies can be chained to handle long, multi-part sequences.

Action Models That Keep Their Word

The PEEK pipeline helps robots see past the clutter. In a typical manipulation task, the robot’s camera picks up everything in the scene — but most of it is irrelevant noise. 

One task demonstrated on the PEEK project page is “give the banana to NVIDIA founder and CEO Jensen Huang”: a photo of Huang sits on a table alongside a photo of Michael Jordan, a collection of unrelated objects and other distractors. 

A human doing the task instantly focuses on the banana and the right photo; a standard robot policy has to process everything and often gets confused. PEEK solves this by having a vision language model read the task instruction and focus the robot’s line of vision accordingly — showing a movement path, and highlighting around the objects that matter, while fading out everything else. 

The policy then acts on that annotated view rather than the raw scene. For a policy trained purely in simulation, adding PEEK produced a 41x real-world improvement in accuracy. For large VLA models and smaller policies, gains range from 2-3.5x. Because it works at the image level, PEEK integrates with any camera-based policy without modification.


Do What You Say — a collaboration with researchers at Carnegie Mellon University, University of Utah and University of Sydney — addresses a specific failure mode that matters more as robots tackle longer, more complex tasks. 

Give a robot an instruction like “store everything on this table inside the cabinet” or “prepare a Manhattan,” and it has to break that down into individual steps and execute them in sequence. 

The problem is that the AI model can correctly reason through what it needs to do — and then execute something different. 

The method, called SEAL, fixes this at runtime without any retraining: the robot generates several candidate action sequences, thinks through where each one would actually lead and picks the outcome that matches what it said it would do. SEAL delivers up to 15% accuracy gains over prior work, with robustness against rephrased instructions, changed objects, scene clutter and shifted camera angles.


In addition to papers, NVIDIA is expanding robotics research infrastructure with large-scale open datasets for robotics. The NVIDIA Physical AI Dataset is the world’s largest open dataset for physical development, surpassing 15 million+ downloads, while NVIDIA Isaac GR00T X Embodiment Sim has become one of the most-downloaded robotics datasets.  

Universities Accelerate Physical AI Research With NVIDIA Technologies

Robotics teams from universities such as Carnegie Mellon University (CMU), ETH Zurich, MIT and University of Texas at Austin are tapping NVIDIA technologies to move physical AI research from simulation to real-world systems — with nearly 50 accepted papers referencing NVIDIA-accelerated simulation, robot learning and compute.

Examples include a paper from CMU demonstrating a robotic control framework trained in NVIDIA Isaac Lab and MIT work on large language model-guided reinforcement learning powered by NVIDIA GPUs.

Explore NVIDIA Research’s physical AI work. Developers can get started with Isaac Lab and Isaac Sim.

Stay up to date by subscribing to our newsletter, and following NVIDIA Robotics on LinkedIn, Instagram, X and Facebook.

To start your robotics journey, enroll in our free NVIDIA Robotics Fundamentals courses today.


NVIDIA GTC Showcases Virtual Worlds Powering the Physical AI Era


Editor’s note: This post is part of Into the Omniverse, a series focused on how developers, 3D practitioners, and enterprises can transform their workflows using the latest advances in OpenUSD and NVIDIA Omniverse.

NVIDIA GTC last week showcased a turning point in physical AI: Robots, vehicles and factories are scaling from single use cases and isolated deployments to sophisticated enterprise workloads across industries. 

At the center of this shift are new frontier models for physical AI, including NVIDIA Cosmos 3, NVIDIA Isaac GR00T N1.7 and NVIDIA Alpamayo 1.5. 

NVIDIA also released the NVIDIA Physical AI Data Factory Blueprint, designed to push the state of the art in world modeling, humanoid skills and autonomous driving, as well as the NVIDIA Omniverse DSX Blueprint for AI factory digital twin simulation.

Open source agentic frameworks such as OpenClaw extend the AI stack all the way to operations — enabling long‑running “claws” that use tools, memory and messaging interfaces to orchestrate workflows, manage data pipelines and execute tasks autonomously on dedicated machines. 

“With NVIDIA and the broader ecosystem, we’re building the claws and guardrails that let anyone create powerful, secure AI assistants,” said Peter Steinberger, creator of OpenClaw, in an NVIDIA press release from GTC. 

OpenUSD is a driving force behind the scalability of physical AI — providing a common, scene‑description language that lets teams bring computer-aided design (CAD) data, simulation assets and real‑world telemetry into a shared, physically accurate view of the world. 

Simulating the AI Factory Before It’s Built

Modern AI factories are complex — spanning thermals, power grids, network load and mechanical systems. Building them on time and on budget becomes much easier when using simulation technology. 

To tackle this, NVIDIA introduced the Omniverse DSX Blueprint at GTC, a reference architecture that unifies simulation across every layer of an AI factory through a single digital twin. This enables operators to optimize performance and efficiency before a rack is installed in the real world.

Compute Is Data: Real-World Data Is No Longer the Moat

Real-world data used to function as a moat for physical AI — but it doesn’t scale. The real world is messy, unpredictable and full of edge cases, and the pipelines to process, simulate and evaluate data are fragmented. The bottleneck isn’t just data — it’s the entire data factory.

To help address this, NVIDIA introduced at GTC its Physical AI Data Factory Blueprint, an open reference architecture that transforms compute into large-scale, high-quality training data. Built on NVIDIA Cosmos open world foundation models and the NVIDIA OSMO operator, it unifies data curation, augmentation and evaluation into a single pipeline, enabling developers to generate diverse, long-tail datasets from limited real-world inputs.

Leading physical AI developers including FieldAI, Hexagon Robotics, Linker Vision, Milestone Systems, Skild AI and Teradyne Robotics are already tapping the blueprint to speed up robotics projects, vision AI agents and autonomous vehicle programs.

Microsoft Azure and Nebius are the first cloud platforms to offer the blueprint, turning world-scale compute into turnkey data production engines.

“Together with cloud leaders, we’re providing a new kind of agentic engine that transforms compute into the high-quality data required to bring the next generation of autonomous systems and robots to life,” said Rev Lebaredian, vice president of Omniverse and simulation technologies at NVIDIA, in this press release. “In this new era, compute is data.”

From OpenUSD to Reality: Seamless Design to Deployment

Converting CAD files to OpenUSD is a critical step in the physical AI pipeline — transforming engineering data into simulation-ready assets that developers can use to build, test and validate robots in physically accurate virtual environments. 

Using tools like the NVIDIA Omniverse Kit software development kit and NVIDIA Isaac Sim, teams can optimize and enrich 3D data for real-time rendering, simulation and collaborative workflows.  

Companies including FANUC and Fauna Robotics are using this seamless CAD-to-OpenUSD workflow to speed up robotic system design and validation.

Transforming Manufacturing and Logistics Through Industrial Digital Twins

“Factories themselves are now robotic systems,” Lebaredian said during his special address on digital twins and simulation at GTC. 

All factories are born in simulation. The NVIDIA Mega Omniverse Blueprint provides enterprises with a reference architecture to design, test and optimize robot fleets and AI agents in a physically accurate facility digital twin before a single robot is deployed on the floor. 

KION, working with Accenture and Siemens, is using this blueprint to build large-scale warehouse digital twins that train and test fleets of NVIDIA Jetson-based autonomous forklifts for GXO, the world’s largest pure-play contract logistics provider. 

Physical AI Steps From Simulation to the Real World

NVIDIA is partnering with the global robotics ecosystem — including leading robot brain developers, industrial robot giants and humanoid pioneers — to enhance production-level physical AI. 

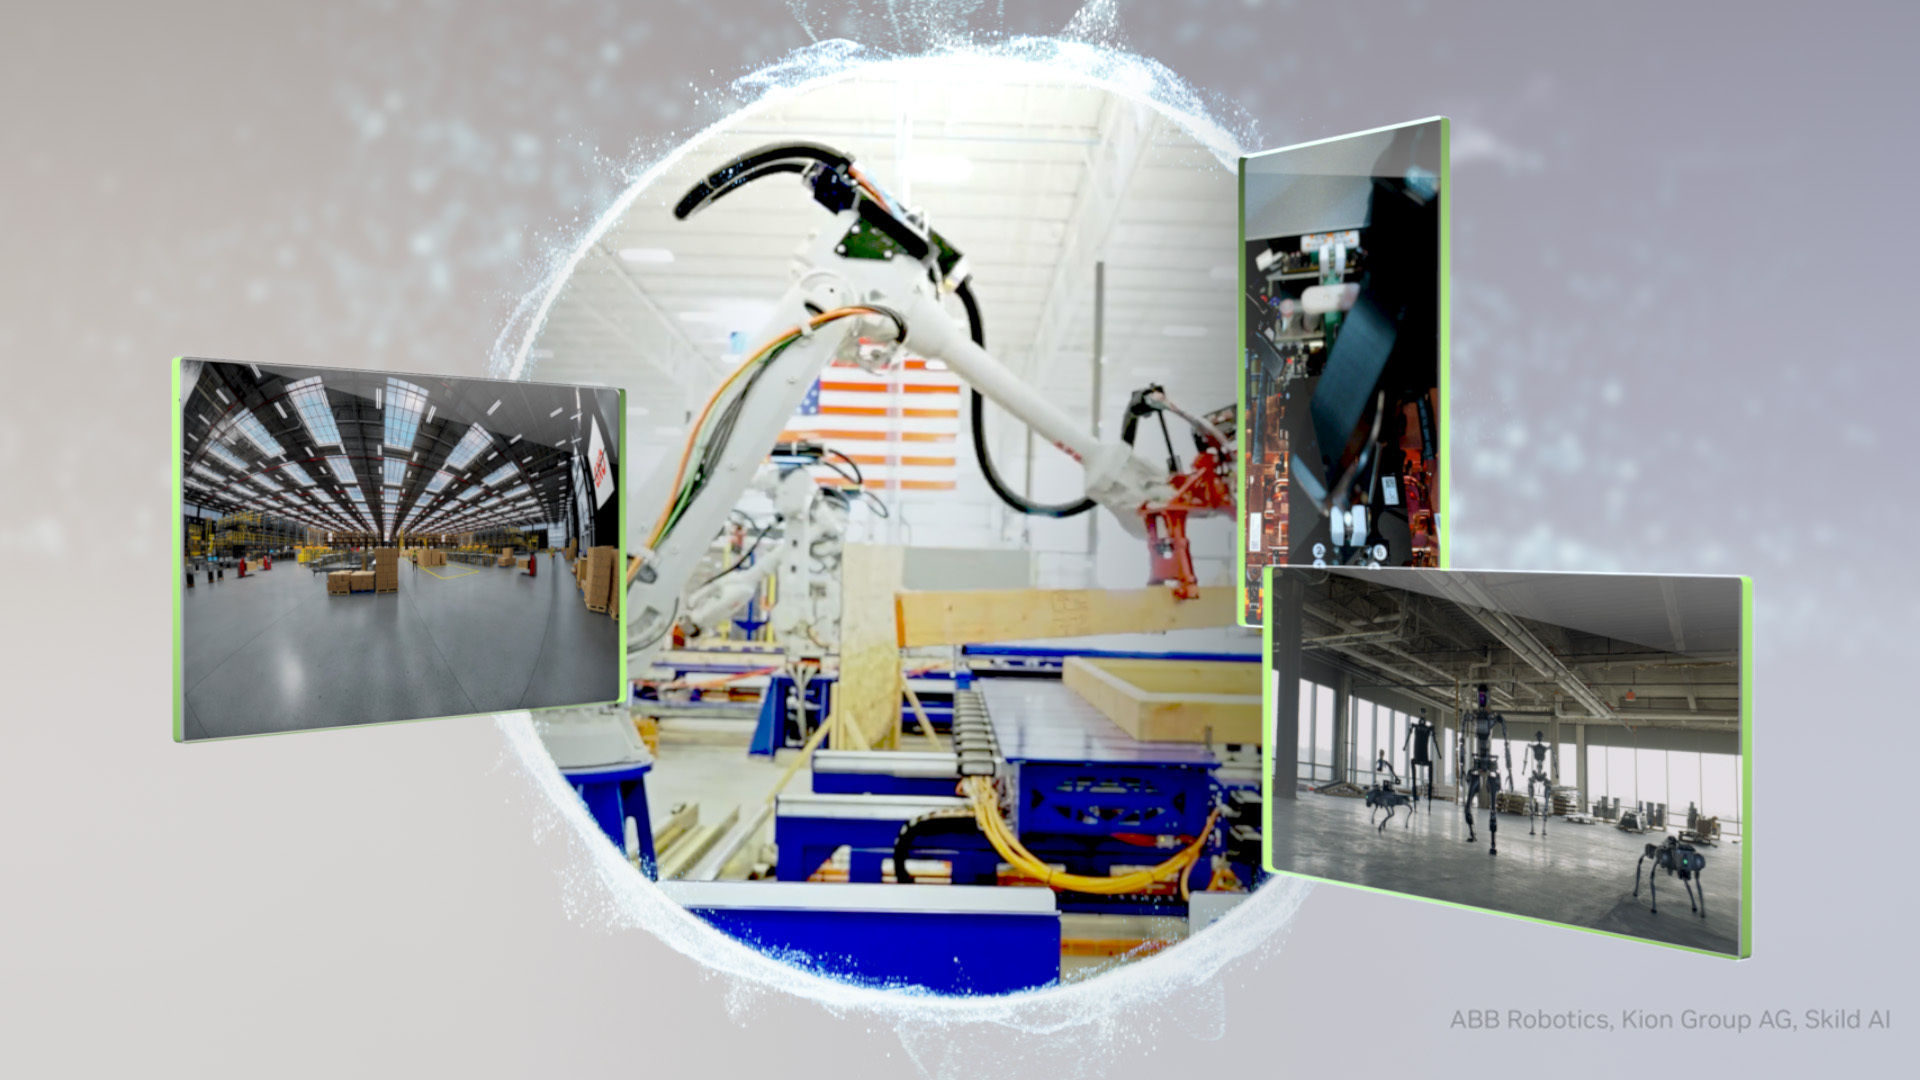
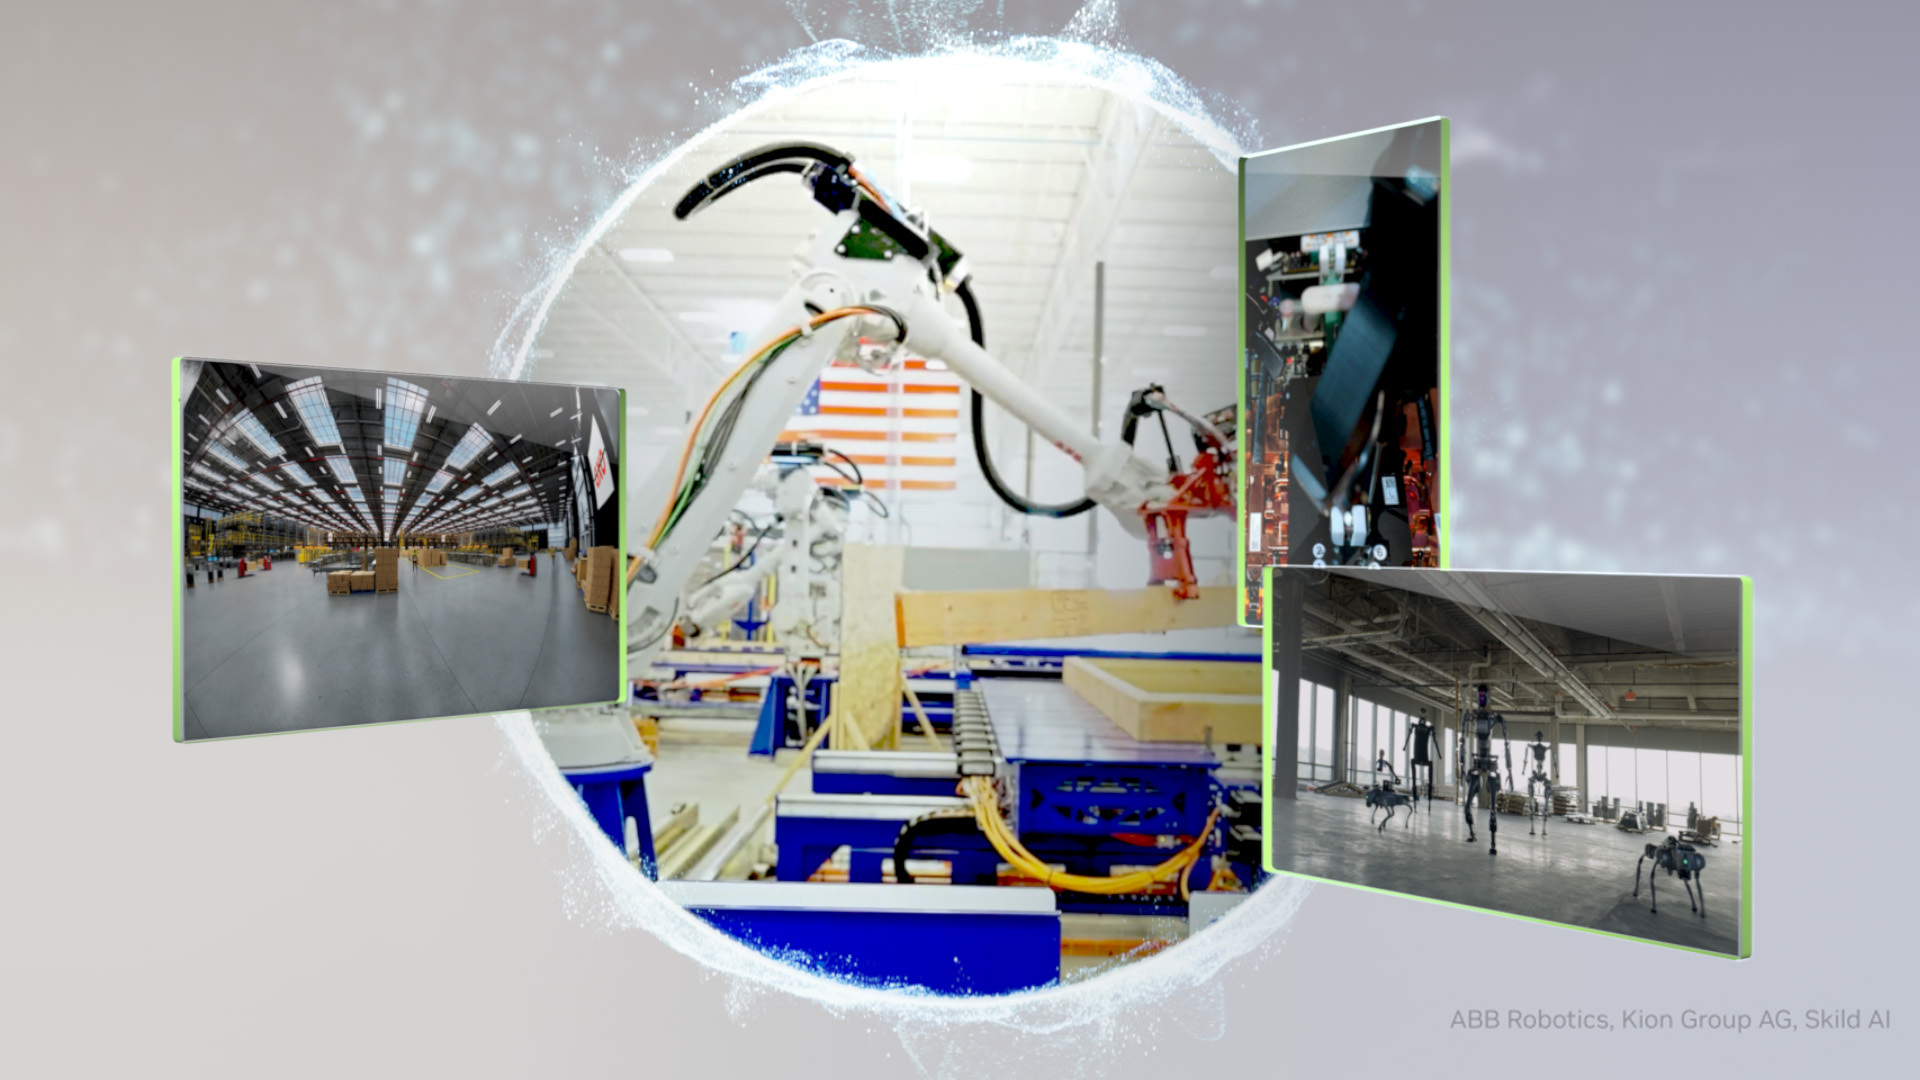
ABB Robotics, FANUC, KUKA and Yaskawa, which have a combined global install base of over 2 million robots, are using NVIDIA Omniverse libraries and NVIDIA Isaac simulation frameworks to validate complex robot applications and production lines through physically accurate digital twins. These companies have also integrated NVIDIA Jetson modules into their controllers to enable real-time AI inference. 

Robot development starts with the robot brains, which is why leading developers including FieldAI and Skild AI are building theirs using NVIDIA Cosmos world models for data generation and Isaac simulation frameworks to validate policies in simulation. 

Meanwhile, Generalist AI is using NVIDIA Cosmos to explore generating synthetic data. This combination allows robots to become proficient in any task — from supply chain monitoring to food delivery — at an exceptional pace. 

Read all of NVIDIA’s announcements from GTC on this online press kit and watch the keynote replay. Catch up on all Physical AI Days sessions from GTC and watch the developer livestream replay.

Everything Will Be Represented in a Virtual Twin, Jensen Huang Says at 3DEXPERIENCE World


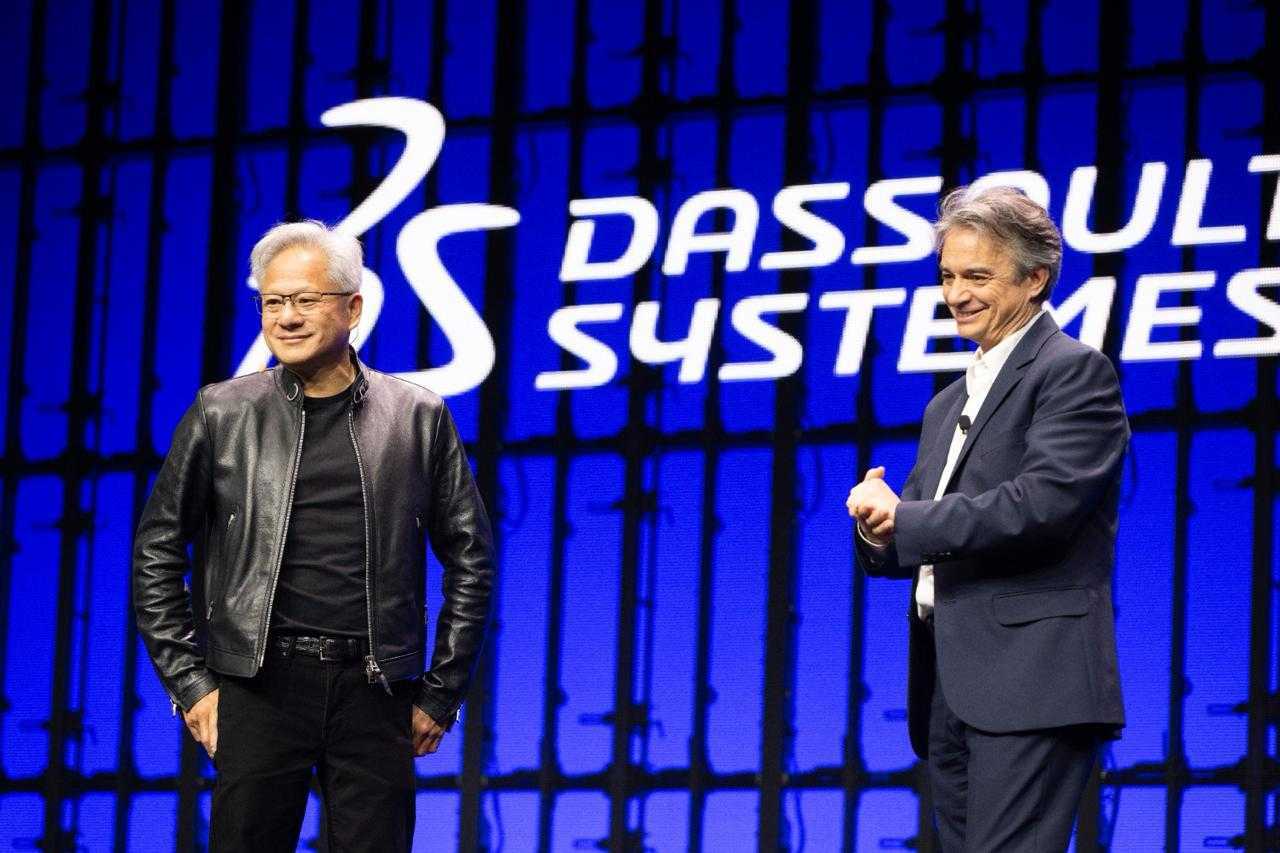
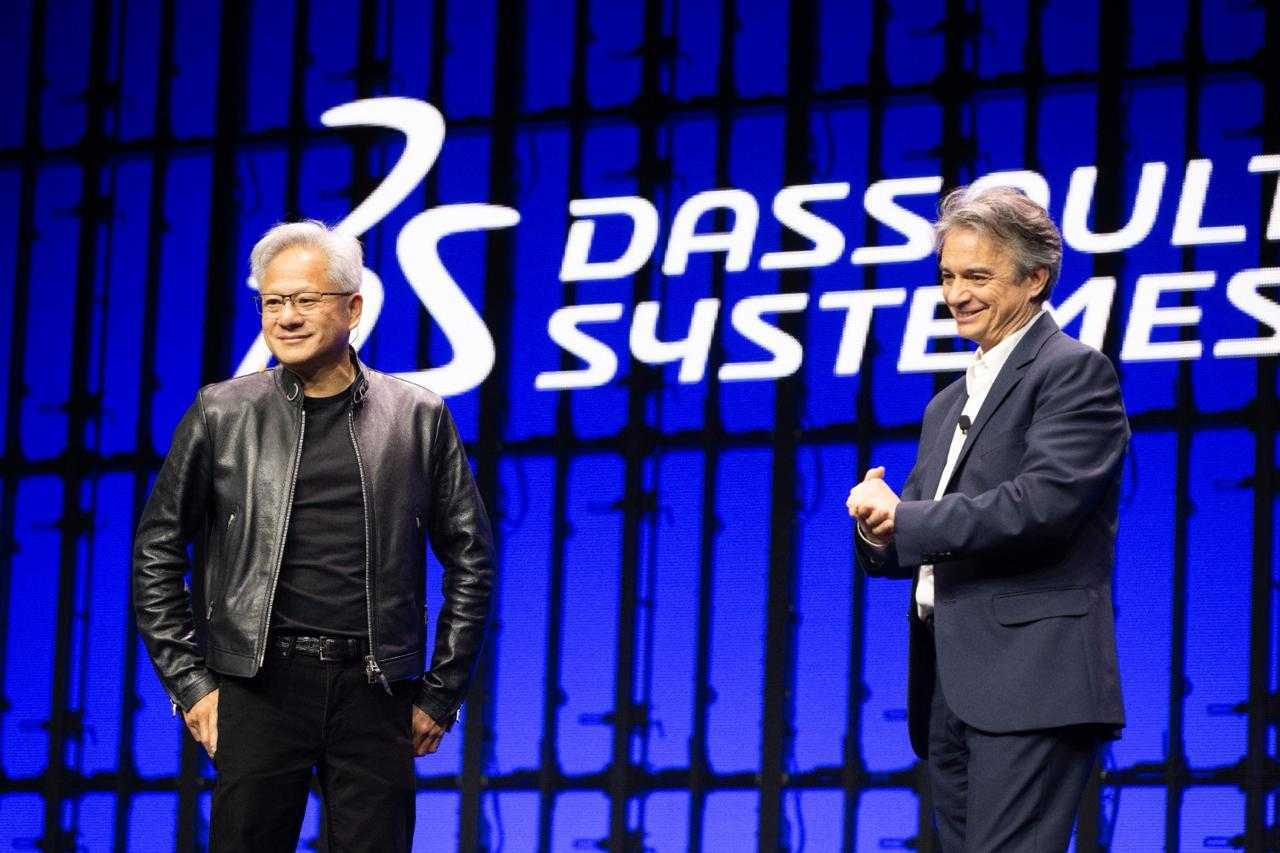
At 3DEXPERIENCE World in Houston, NVIDIA founder and CEO Jensen Huang and Dassault Systèmes CEO Pascal Daloz laid out a blueprint for industrial AI rooted in physics-based “world models” — systems designed to simulate products, factories and even biological systems before they’re built.

“Artificial intelligence will be infrastructure,”  like water, electricity, and the internet Huang told the crowd, playfully referring to the engineering-heavy audience as “Solid Workers,” a nod to Dassault Systèmes’ SolidWorks platform.

The announcement continues a collaboration spanning more than a quarter century between NVIDIA and Dassault Systèmes.

“This is the largest collaboration our two companies have ever had in over a quarter century,” Huang said. “We’re going to fuse these technologies so engineers can work at a scale that’s 100 times, 1,000 times — and eventually a million times greater than before.”

The new partnership brings NVIDIA accelerated computing and AI libraries together with Dassault Systèmes’ Virtual Twin platforms to move more engineering work into real-time digital workflows, powered by AI companions that help teams explore, validate, prototype and iterate faster.

Huang framed the shift as a reinvention of the computing stack: moving from hand-specified, structured digital designs to systems that can generate, simulate and optimize in software — at industrial scale.

From Digital Models to Industry World Models

Virtual twins are not applications, “they are knowledge factories,” Daloz said.

The partnership aims to establish industry world models — science-validated AI systems grounded in physics that can serve as mission-critical platforms across biology, materials science, engineering and manufacturing.

In Daloz’s framing, the value moves upstream: virtual twins become the place where knowledge is created, tested, and trusted — before anything is built in the physical world.

Dassault Systèmes, whose 3DEXPERIENCE platform serves more than 45 million users and 400,000 customers globally, has long been a leader in virtual twin technology — digital replicas that let engineers simulate products and processes before building them physically.

The collaboration brings together accelerated computing, AI and digital twin technologies so engineers can design not only geometry, but behavior — and explore radically larger design spaces earlier in development.

Together, the companies outlined how this shared architecture will show up across science, engineering and manufacturing workflows:

  • Advancing Biology and Materials Research​: The NVIDIA BioNeMo platform and BIOVIA science-validated world models accelerate the discovery of new molecules and next-generation materials.
  • AI-Driven Design and Engineering: SIMULIA AI-based Virtual Twin Physics Behavior leveraging NVIDIA CUDA-X libraries and AI physics libraries empowers designers and engineers to accurately and instantly predict outcomes.
  • Virtual Twins for Every Factory: NVIDIA Omniverse physical AI libraries integrated into the DELMIA Virtual Twin enable autonomous, software-defined production systems.
  • Virtual Companions Supercharge Dassault Systèmes’ Users: The 3DEXPERIENCE agentic platform, combining NVIDIA AI technologies and NVIDIA Nemotron open models with Dassault Systèmes’ Industry World Models, powers Virtual Companions to tap into deep industrial context, delivering trusted, actionable intelligence.

Huang said that in domains like biology and materials, the frontier is learning the underlying “language” of complex systems and then generating new options that can be evaluated and validated in simulation.

Designing and Operating the Factory in Software

A central theme of the discussion was how factories themselves are changing — from static physical assets to living systems that are designed, simulated and operated as virtual twins.

As part of the partnership, Dassault Systèmes is deploying NVIDIA-powered AI factories on three continents through its OUTSCALE sovereign cloud, enabling customers to run AI workloads while maintaining data residency and security requirements.

Both executives emphasized that the goal isn’t to replace engineers — it’s to amplify them. As AI agent companions take on more exploratory and repetitive tasks, designers and engineers gain leverage and creativity, not redundancy.

AI Companions That Expand Human Creativity

Every designer will have a “team of companions,” Huang said — a shift he described as fundamentally positive for engineers, software platforms and the broader ecosystem built on them.

For the tens of millions of engineers who use Dassault Systèmes tools to design everything from aircraft to consumer packaged goods, the shift isn’t about replacing human creativity — it’s about expanding it.

“Success is not about automation,” Daloz said. “[Engineers] don’t want to automate the past — they want to invent the future.”

Looking ahead, Daloz framed the partnership as about more than performance gains – it’s an effort to open new possibilities, help companies eliminate bad choices before they become expensive mistakes, and create entirely new categories of products.

“Virtual twins and the 3D Universes are not applications,” Daloz said. “They are knowledge factories.”

The fireside conversation between Huang and Daloz was broadcast live from 3DEXPERIENCE World.