Skild AI Taps NVIDIA Physical AI to Teach Robots New Tasks From a Single Video


Manufacturing floors, warehouses and production lines rarely stay fixed — tasks change, layouts shift and new products arrive, and most robots can’t keep up without significant reprogramming.

Skild AI’s new S1 robot foundation model helps address this, designed to learn previously unseen, long-horizon tasks from a single video demonstration. The model, launched last week, uses video as input to understand and execute the task without updating its weights or undergoing task-specific post-training — a technique called in-context learning.  

Skild built S1 and conducted the research on NVIDIA AI infrastructure, part of a broader collaboration spanning synthetic data generation, model training, simulation and real-world physical AI deployment. The companies are working together to move adaptable robot intelligence from the lab into factories and other dynamic operating environments.

“Learning by experience, and not preprogramming, is the step change that has happened in robotics,” said Deepak Pathak, cofounder and CEO of Skild AI. “NVIDIA Isaac Lab and NVIDIA Cosmos technologies help Skild create the scalable, diverse experience its robots need to learn across many scenarios and embodiments.”

The launch comes as the company reached a $100 million annual revenue run rate 10 months after its first commercial deployment. In that time, Skild has built more than 60 deployment partnerships with work spanning manufacturing, logistics, inspection, security, food preparation and other applications. 

Learning New Work From One Video

Most industrial robots are built for fixed jobs, so each new product, process or layout requires more data, retraining and validation.

S1 takes a different approach: An operator records a video of the desired task and provides it to the model as a prompt. It interprets the demonstrated intent, objects and sequence, then maps them into actions for the robot in front of it — with no retraining — and often for a task not covered by its pretraining dataset. 

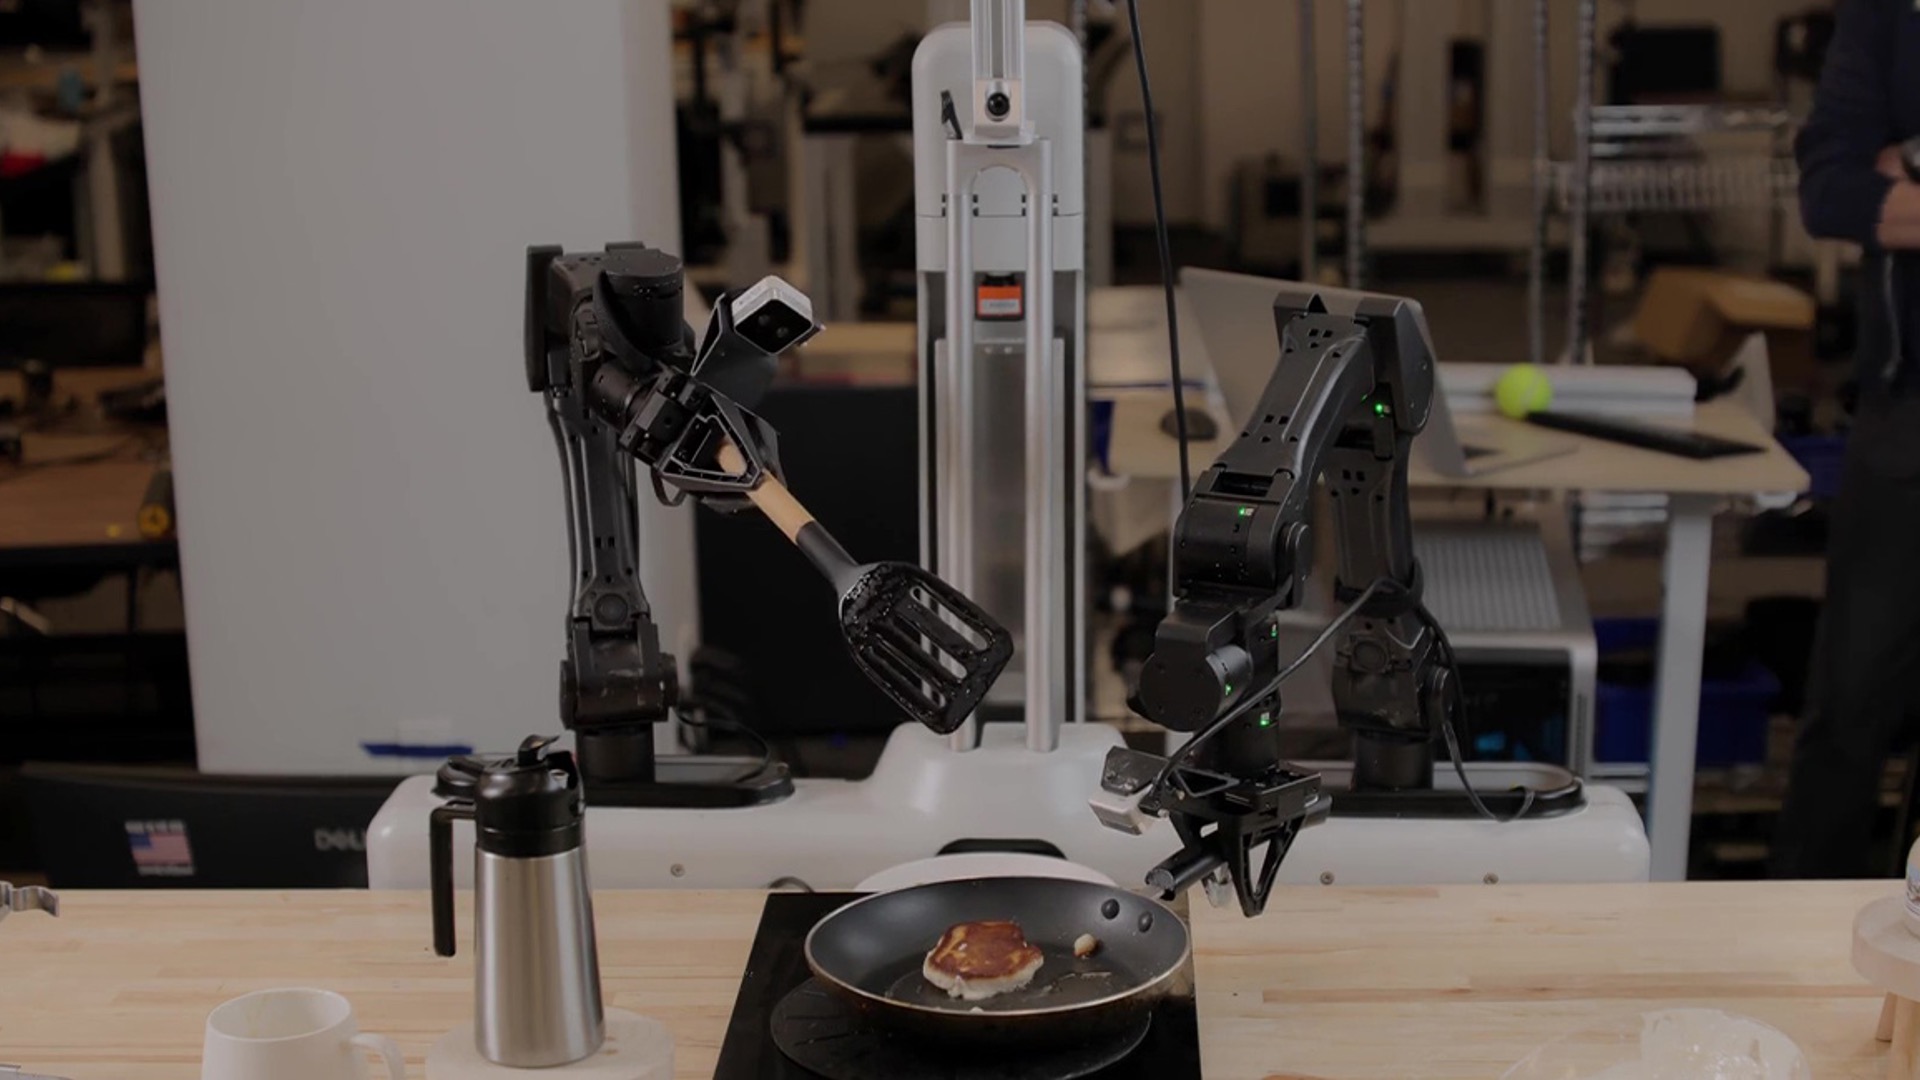
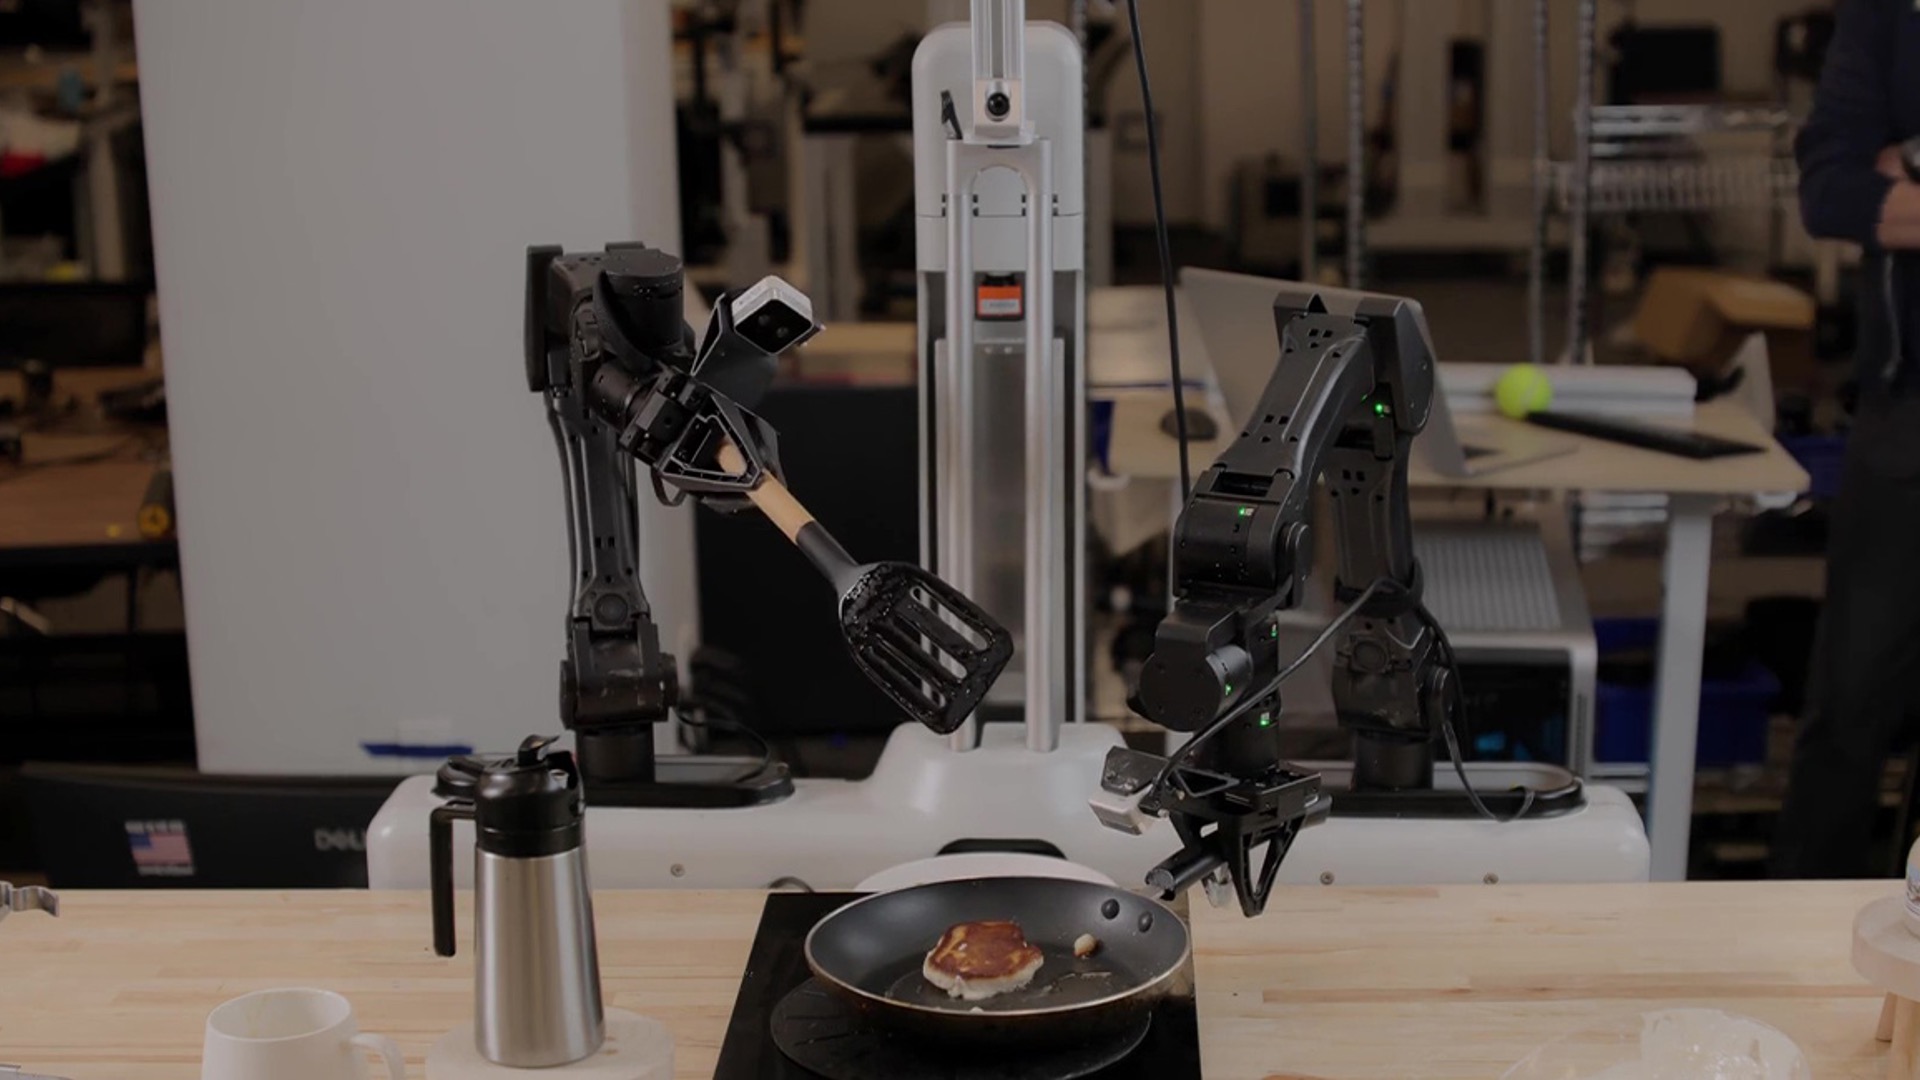
S1 can perform unfamiliar tasks lasting up to 10 minutes, including plant potting, pancake making, pour-over coffee brewing and kit assembly. These tasks can span dozens of manipulation steps and require the robot to compose skills in sequences it hasn’t previously performed. 


In one plant-potting test, the Skild AI team moved from recording the demonstration to autonomous execution on hardware in just 11 minutes. The model can also adjust when objects move, recover from errors and combine skills in sequences that weren’t explicitly programmed.

In Skild’s tests on new, multistep tasks, its S1 robot succeeded about 66% of the time at each step, compared with 9% for a similar AI system — a more than sevenfold improvement. Skild also estimates that showing the robot one short video example can be as useful as giving it roughly 380 hands-on training examples. A person collecting those examples manually could take 50-100 hours.

From Research to Factory Work

S1 breaks the cycle of needing to constantly retrain robots for new factors by letting operators demonstrate new tasks directly without requiring a new dataset or training run for every change. Where customer agreements permit, experience from Skild’s commercial deployments can inform the broader model and help accelerate future deployments.

That work is already in action on the factory floor. Skild, NVIDIA and Foxconn are deploying the Skild Brain on dual-arm manipulators for high-precision assembly of NVIDIA Blackwell systems. In one demonstrated workflow, a robot installs a busbar and limit block, fastens 16 screws and adapts to disturbances across a multistep task. The work requires precise motion, contact-aware control, sequence tracking and recovery when the scene differs from the plan.


NVIDIA Technology Across the Development Cycle

NVIDIA accelerated computing gives Skild the scale to train its shared robot brain using simulation, human video, teleoperation and, where permitted, deployment data. NVIDIA Cosmos open world foundation models help diversify training data and turn video into structured descriptions, while Cosmos Curator helps annotate, filter and organize data at scale.

Skild is extensively using NVIDIA’s open simulation frameworks to train and validate its robot brain before real-world deployment. NVIDIA Omniverse libraries and the NVIDIA Isaac Sim framework provide physically based virtual environments for generating data, testing edge cases and validating behaviors.

Skild further strengthens the skills of its brain through reinforcement learning in Isaac Lab, an open modular robot learning framework. Powered by the Newton physics engine, Isaac Lab helps Skild’s engineers accurately model various physical parameters, such as forces, contact, collision and pressure, and reduce the simulation-to-reality gap.

Skild and NVIDIA are also jointly developing new GPU-accelerated simulation solvers that quickly and accurately model how robots physically touch, grip and manipulate solid objects. They’ll soon be made available to all developers as part of Newton. 

As models move toward production, NVIDIA Nsight tools help engineers find performance bottlenecks during training, and the NVIDIA TensorRT software development kit optimizes inference so robots can respond quickly in the physical world. Together, these technologies connect the data, simulation, training and deployment stages instead of treating them as separate systems.

Read Skild AI’s S1 research and explore the NVIDIA Isaac robotics platform.

NVIDIA Open Sources First GPU-Accelerated Medical Physics Simulation Framework


Before a healthcare robot can be useful in the real world, it has to learn how the physical world pushes back. Anatomy varies. Instruments bend, press, slip and interact with tissue. Imaging can be noisy or incomplete. And the rare, edge scenarios developers most need to understand don’t appear on schedule.

That creates one of the biggest bottlenecks in healthcare robotics: obtaining the enormous amount of varied data developers need to train, test and improve robot behavior.  

NVIDIA Medical Physics Simulation framework — a new open source, GPU-accelerated capability within NVIDIA Isaac for Healthcare — announced today, helps medical robotics developers model anatomy-device interaction, generate hard-to-capture scenarios, test in silico, and train or evaluate robot policies before hardware-heavy testing. 

The framework brings together anatomy and medical device behavior with sensor simulation and robot learning so teams can create reusable simulation environments instead of rebuilding custom scenes for every workflow, saving developers time and bringing innovations to market faster. 

Because Medical Physics Simulation is open source, healthcare robotics developers can inspect the framework, adapt it to their own devices and workflows, and build on a GPU-accelerated foundation that works seamlessly with the broader NVIDIA stack.

Open source is especially important in healthcare because teams need transparency into the data, models and weights that shape system behavior. Access to open models and model weights can help developers reproduce results, evaluate performance across different anatomies and scenarios, identify limitations and build evidence for regulatory review. 

A Virtual Training Ground for Medical Robots

For physical AI, experience is data in motion. Developers need to train robots to operate properly even when anatomy changes, devices behave differently, conditions shift or a policy fails unexpectedly.

Medical Physics Simulation helps developers simulate anatomy, device contact, friction and sensor inputs, then test in interactions and environments to evaluate how robots perform across those changes. Powered by NVIDIA CUDA and part of Isaac for Healthcare — built on the NVIDIA Warp, Newton and Cosmos simulation and generative AI technologies — the framework can run hundreds of parallel simulation environments, helping teams explore more scenarios and identify failure modes earlier in development. 

For robot builders, this turns simulation from a bespoke engineering project into reusable infrastructure. The difference now is scale: benchmarks show 8,192 robot-training environments running in parallel with GPU-native simulation cut training from over five hours to under two minutes. 

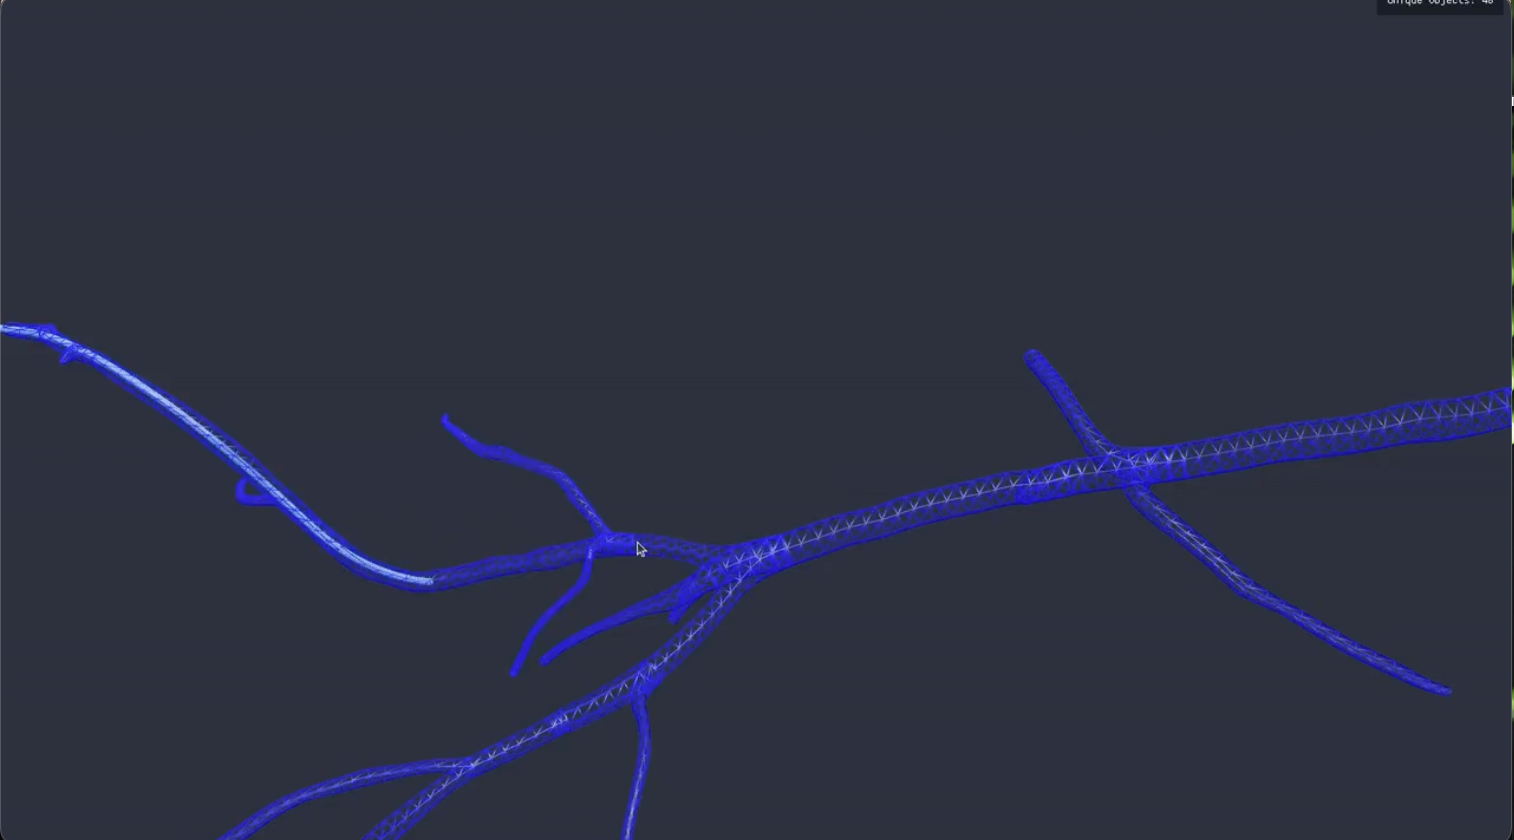
With this framework, developers can connect vascular anatomy, flexible instruments such as catheters and guidewires, simulated X-ray imaging and reinforcement learning. The framework is designed to extend beyond that example to additional devices, anatomies, sensors and healthcare robotics domains.

Medical Physics Simulation brings together classical physics simulation and generative AI physics simulation. Classical simulation helps model known physical rules, such as device contact, friction and motion. NVIDIA Cosmos-H Dreams, the real-time generative AI physics simulation capability within Medical Physics Simulation, helps model visual scene dynamics learned from procedural data.

Together, these approaches give developers a richer way to build and test healthcare robotics systems in virtual environments before moving to physical prototypes and lab testing.

An Ecosystem Building the Future of Medical Robotics

Medical robotics leaders are already applying simulation-driven development to solve specific surgical challenges.

CMR Surgical and Cambridge Consultants, part of Capgemini, are using Cosmos-H-Dreams to implicitly learn interaction physics for soft-tissue surgical procedures and generate patient-specific simulations. CMR contributed nearly 500 hours of anonymized clinical data from its Versius Surgical Robotic System to the Open-H Embodiment open dataset, benefiting procedures including cholecystectomy, prostatectomy, hernia repair and hysterectomy.

“Open source models allow us to build on shared knowledge, accelerating responsible innovation and, ultimately, gives us the potential to deliver more consistent care and better outcomes for patients worldwide,” said Chris Fryer, chief technology officer at CMR Surgical.

Johnson & Johnson MedTech is using Isaac for Healthcare’s Medical Physics Simulation and a Cosmos-based foundation model to build digital twins of its endoluminal MONARCH platform for urology, modeling complex anatomy and kidney-stone scenarios.

XCath is using the Medical Physics Simulation for endovascular autonomy policy training. Inner Logic is accelerating the evolution of medical technology with synthetic data, validating device mechanics and producing in silico evidence to support regulatory pathways with NVIDIA Medical Physical Simulation.

Medtronic Structural Heart is exploring applying Medical Physics Simulation with simulated X-ray sensing to generate data for catheter navigation research.

A New Layer in the Isaac for Healthcare Stack

As a modular capability within NVIDIA Isaac for Healthcare, Medical Physics Simulation can be used on its own or alongside digital twin pipelines, medical sensor simulation, the NVIDIA Isaac Lab open robot-learning framework and NVIDIA open models and policies.

Developers can explore the open source Medical Physics Simulation framework, review available reference workflows and start building simulation environments for their own devices, anatomies and healthcare robotics applications.